Ranger
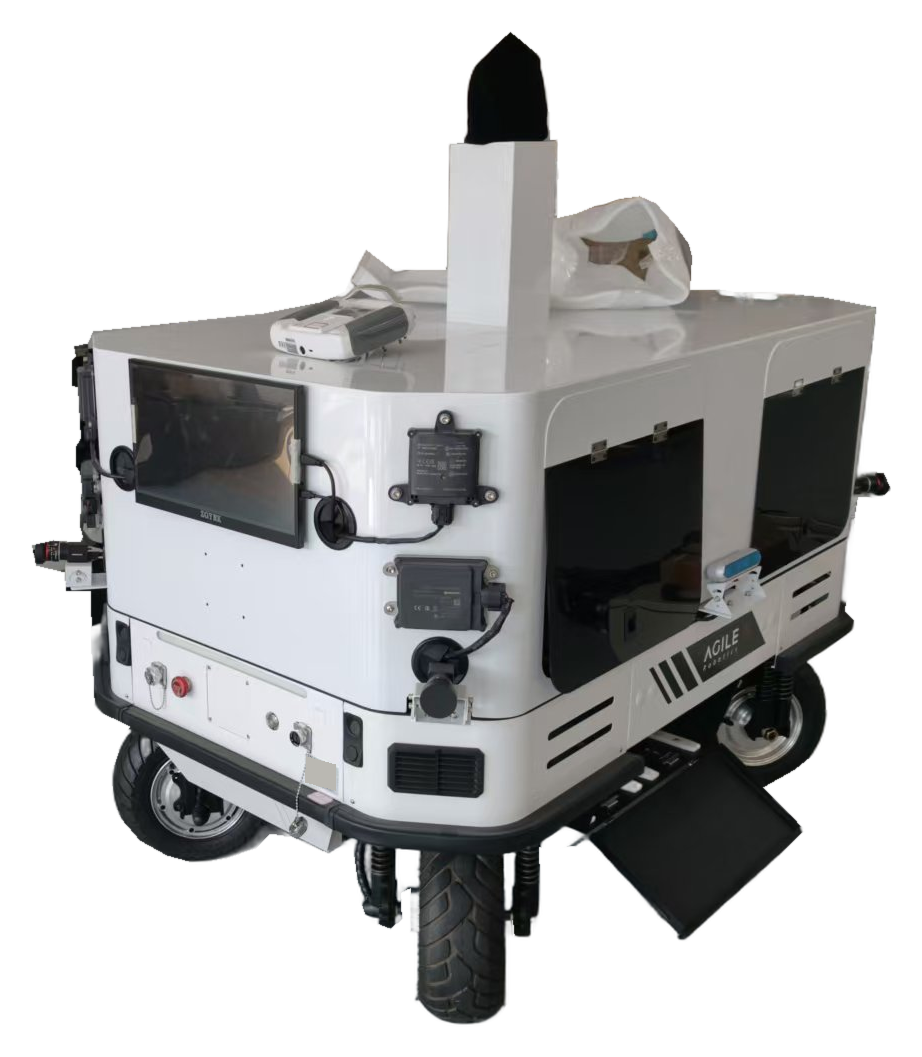
AgileX Robotics
A research platform for multi-sensor perception and autonomous driving.
OMEGA Lab sensor-equipped platform.
OMEGA LAB / RESEARCH PLATFORMS
Built for embodied research.
Autonomous vehicles, aerial robots, manipulation systems, humanoids, teleoperation, and AI computing for embodied research.
Connected and autonomous vehicles for intelligent transportation, perception, and planning.
AgileX Robotics
A research platform for multi-sensor perception and autonomous driving.
OMEGA Lab sensor-equipped platform.
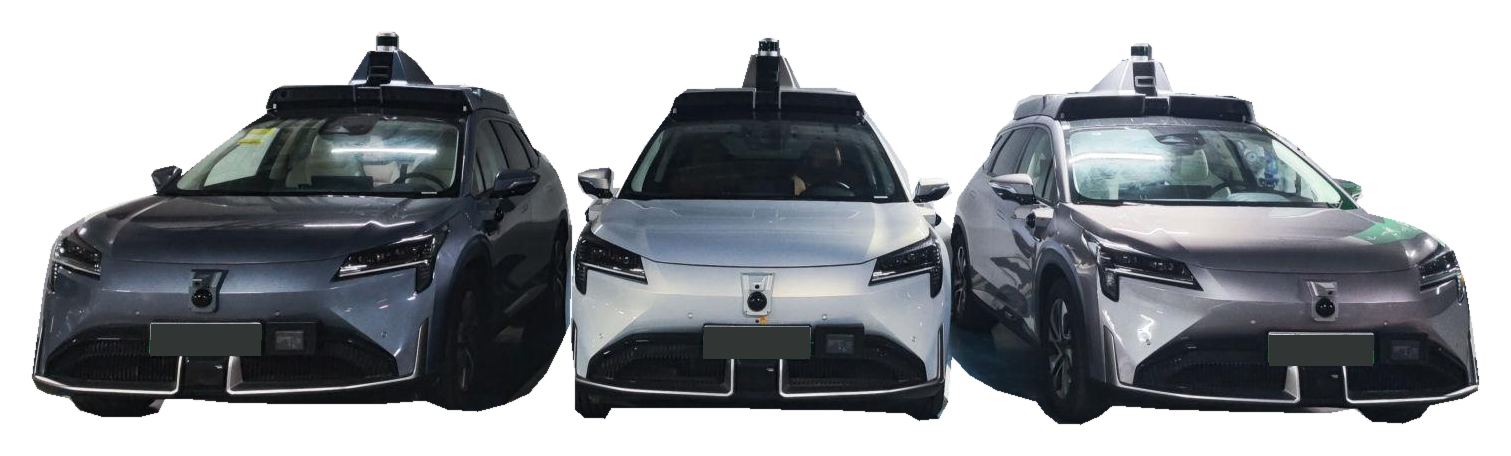
AION · OMEGA Lab
A fleet of full-size vehicles equipped for multi-sensor perception, autonomous driving, and intelligent transportation research.
OMEGA Lab research fleet.
Aerial platforms for autonomous flight and field robotics.
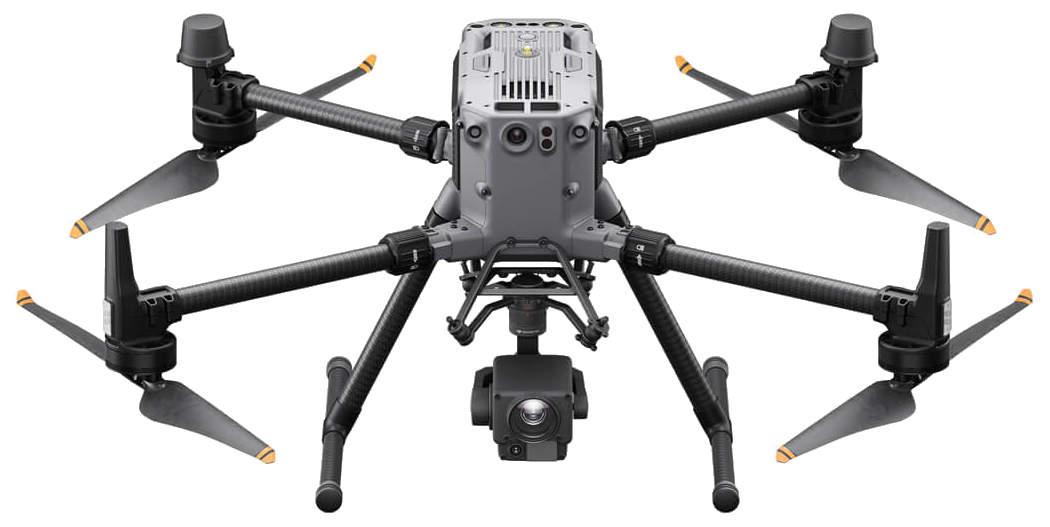
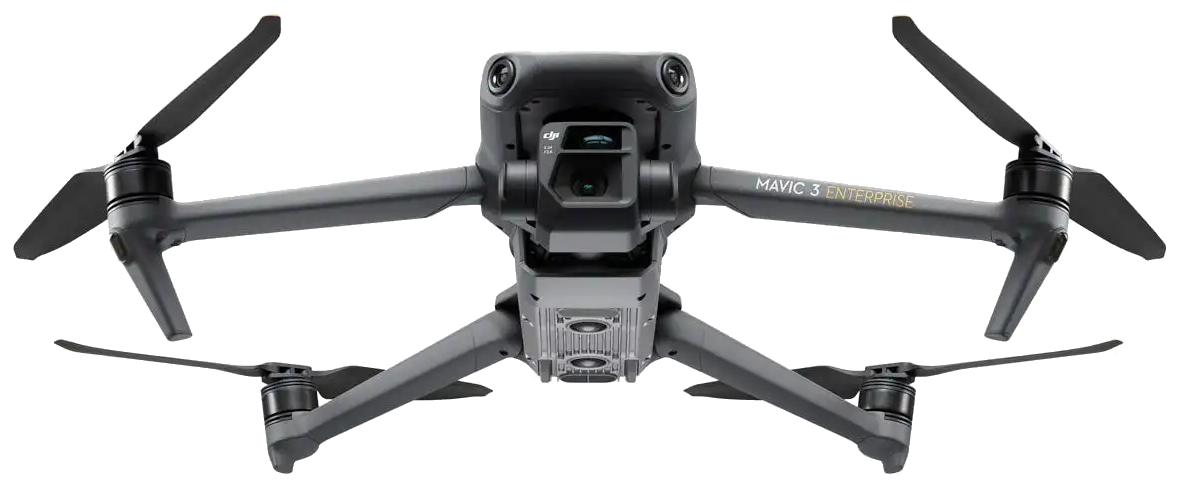
DJI
An enterprise aerial platform for field sensing and aerial robotics research.
DJI
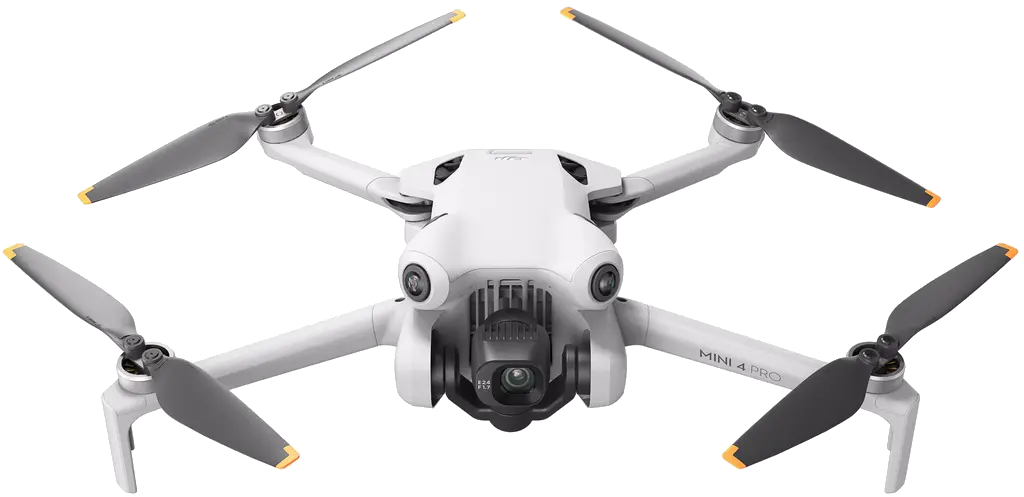
A compact enterprise drone for mapping, aerial observation, and field experiments.
DJI
A lightweight aerial platform for observation and field data collection.
ZHT Aero
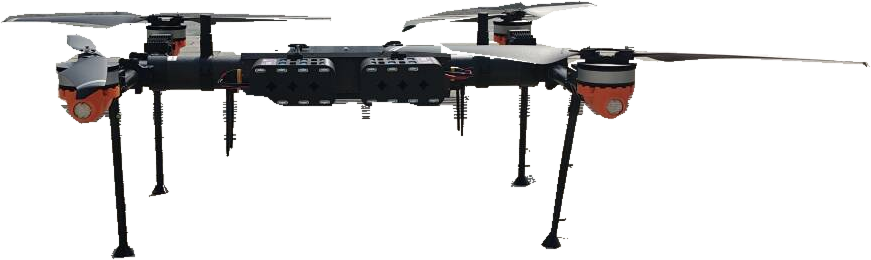
A modular quadrotor platform for aerial research and field experiments.
DiffRobot
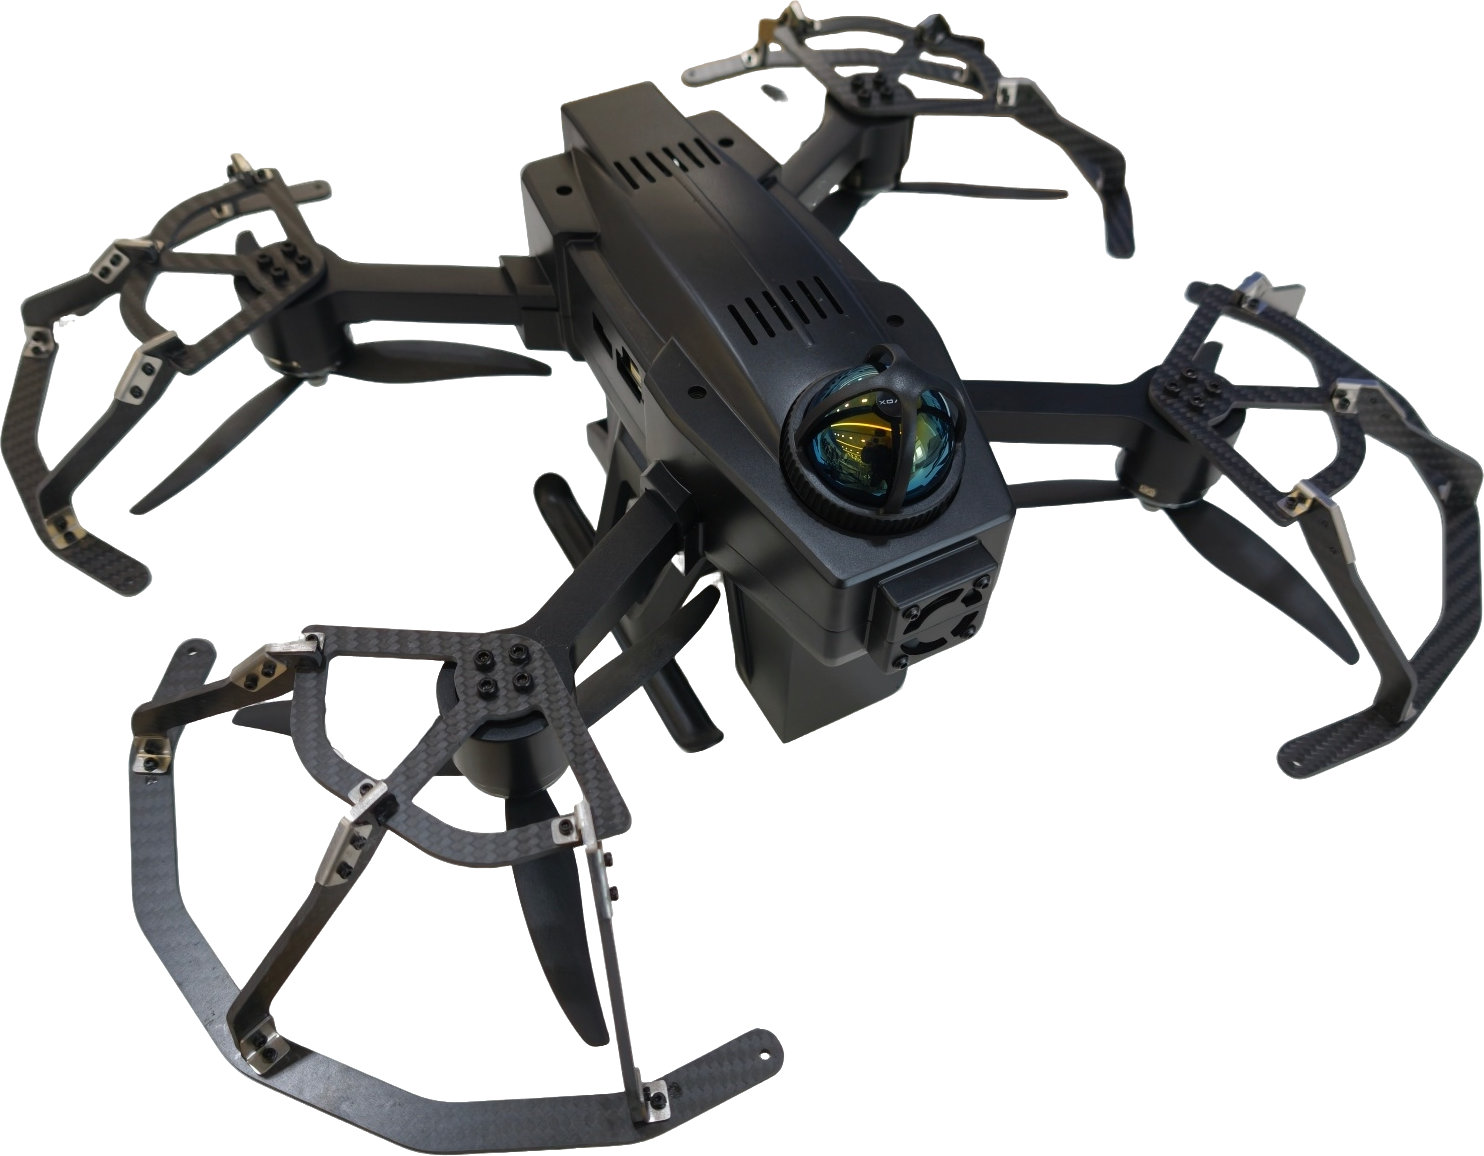
A research UAV platform for autonomous navigation and aerial robotics.
Robot arms, dexterous hands, and mobile bases for manipulation and navigation research.
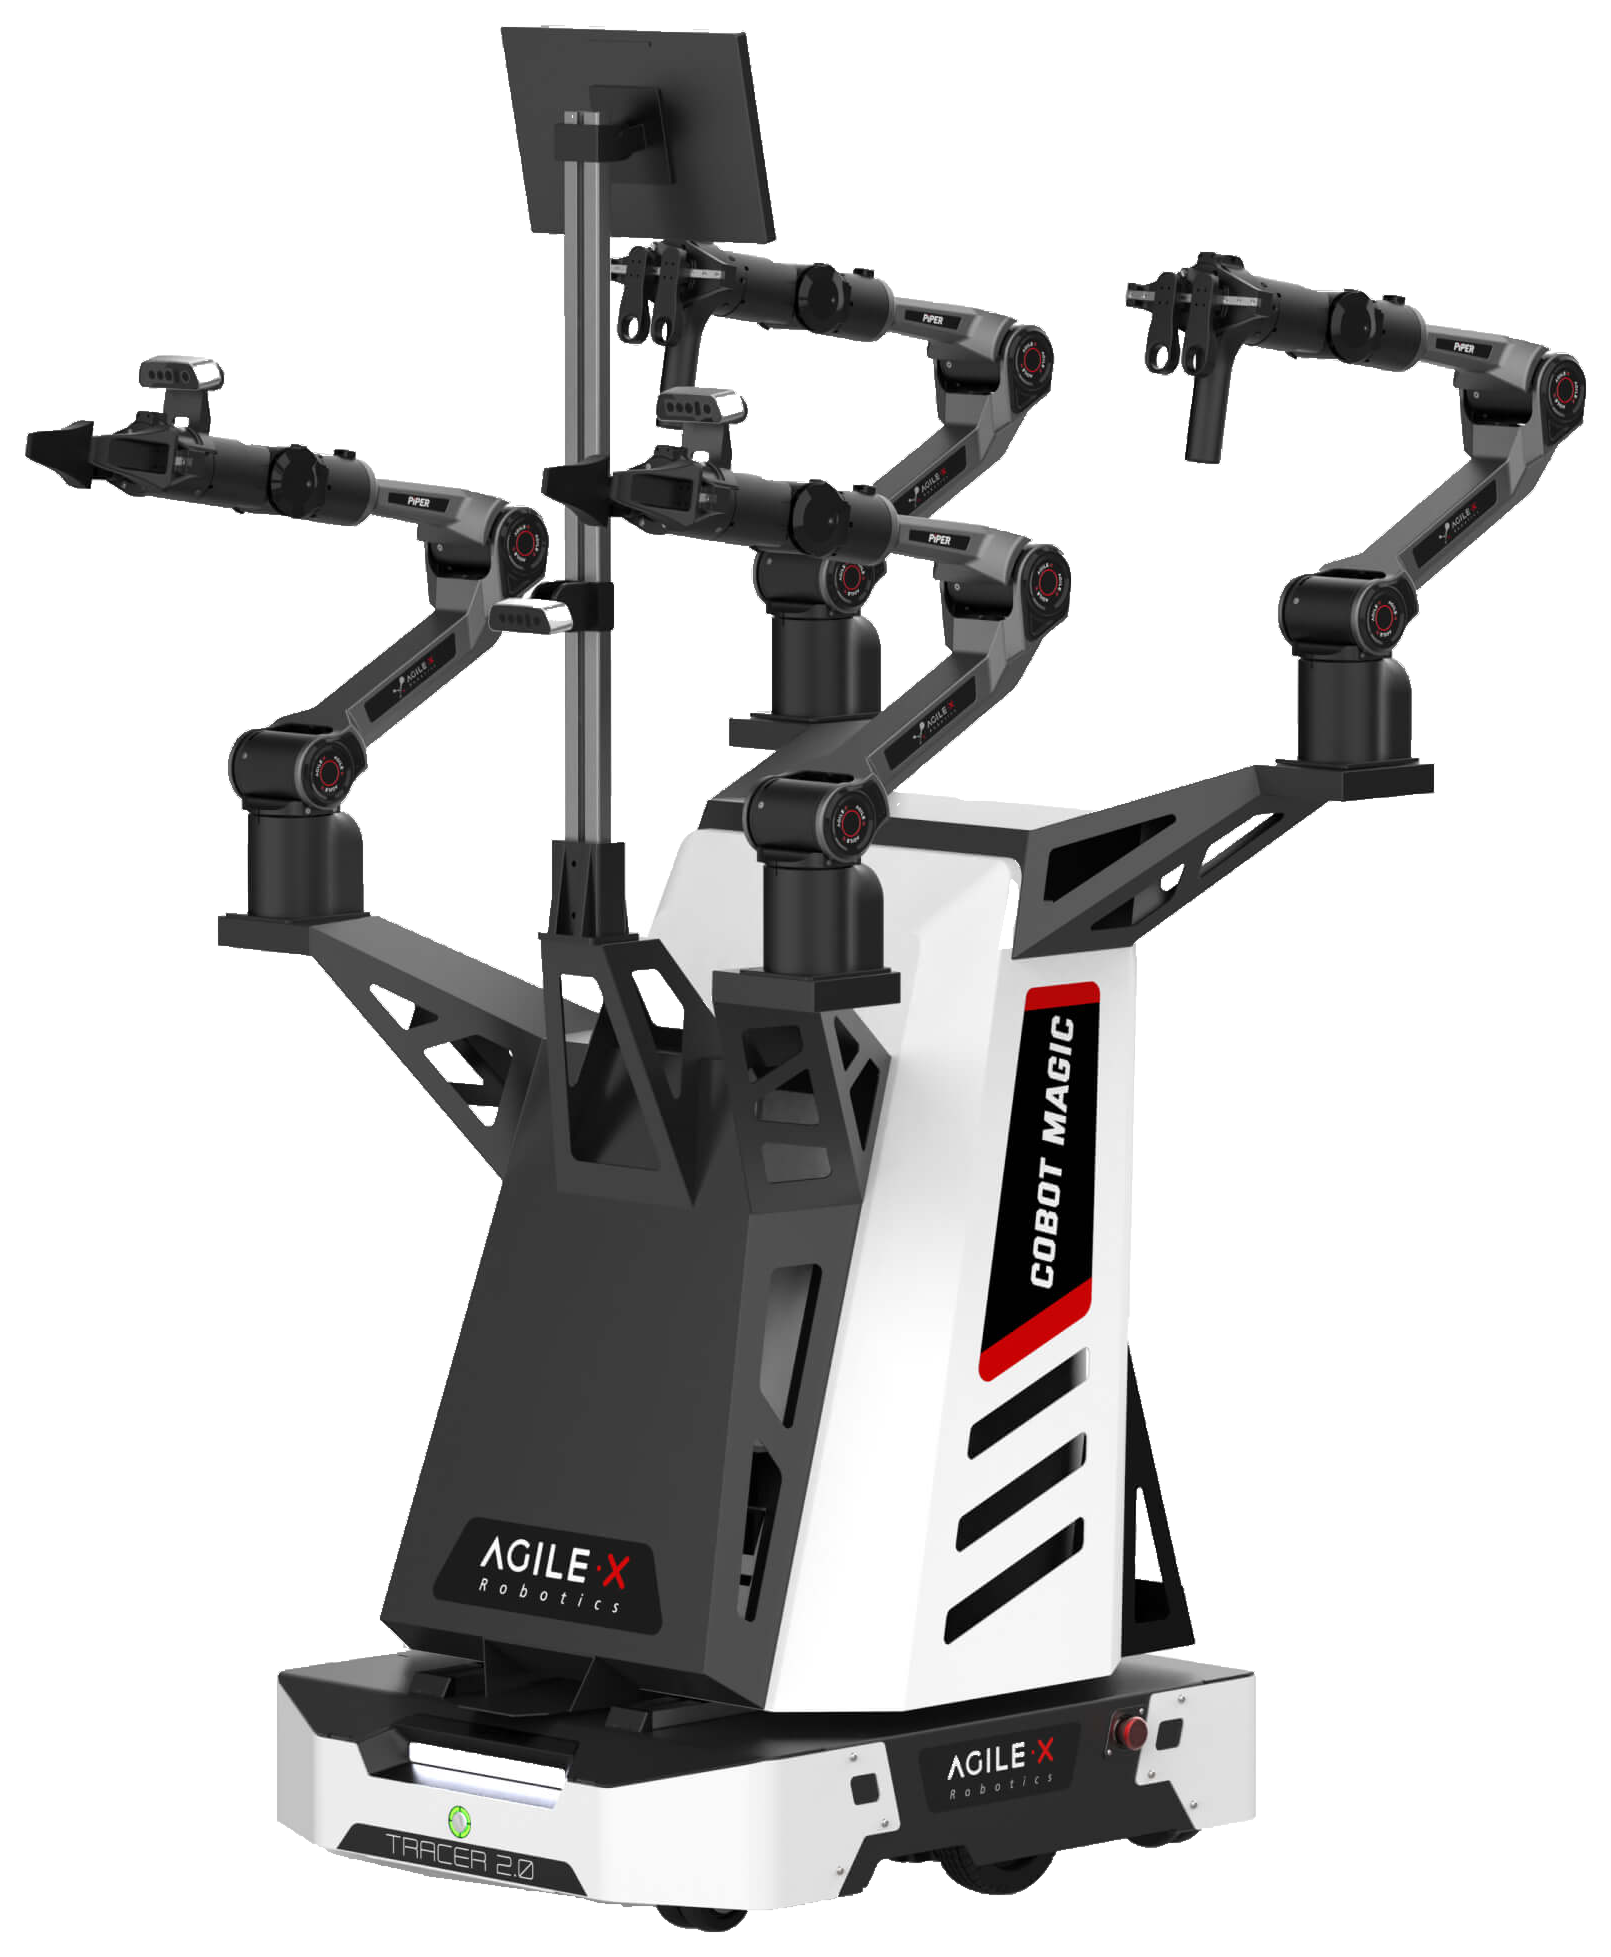
AgileX Robotics
A mobile bimanual platform for whole-body teleoperation, demonstration collection, and robot learning.
Manufacturer configuration shown.
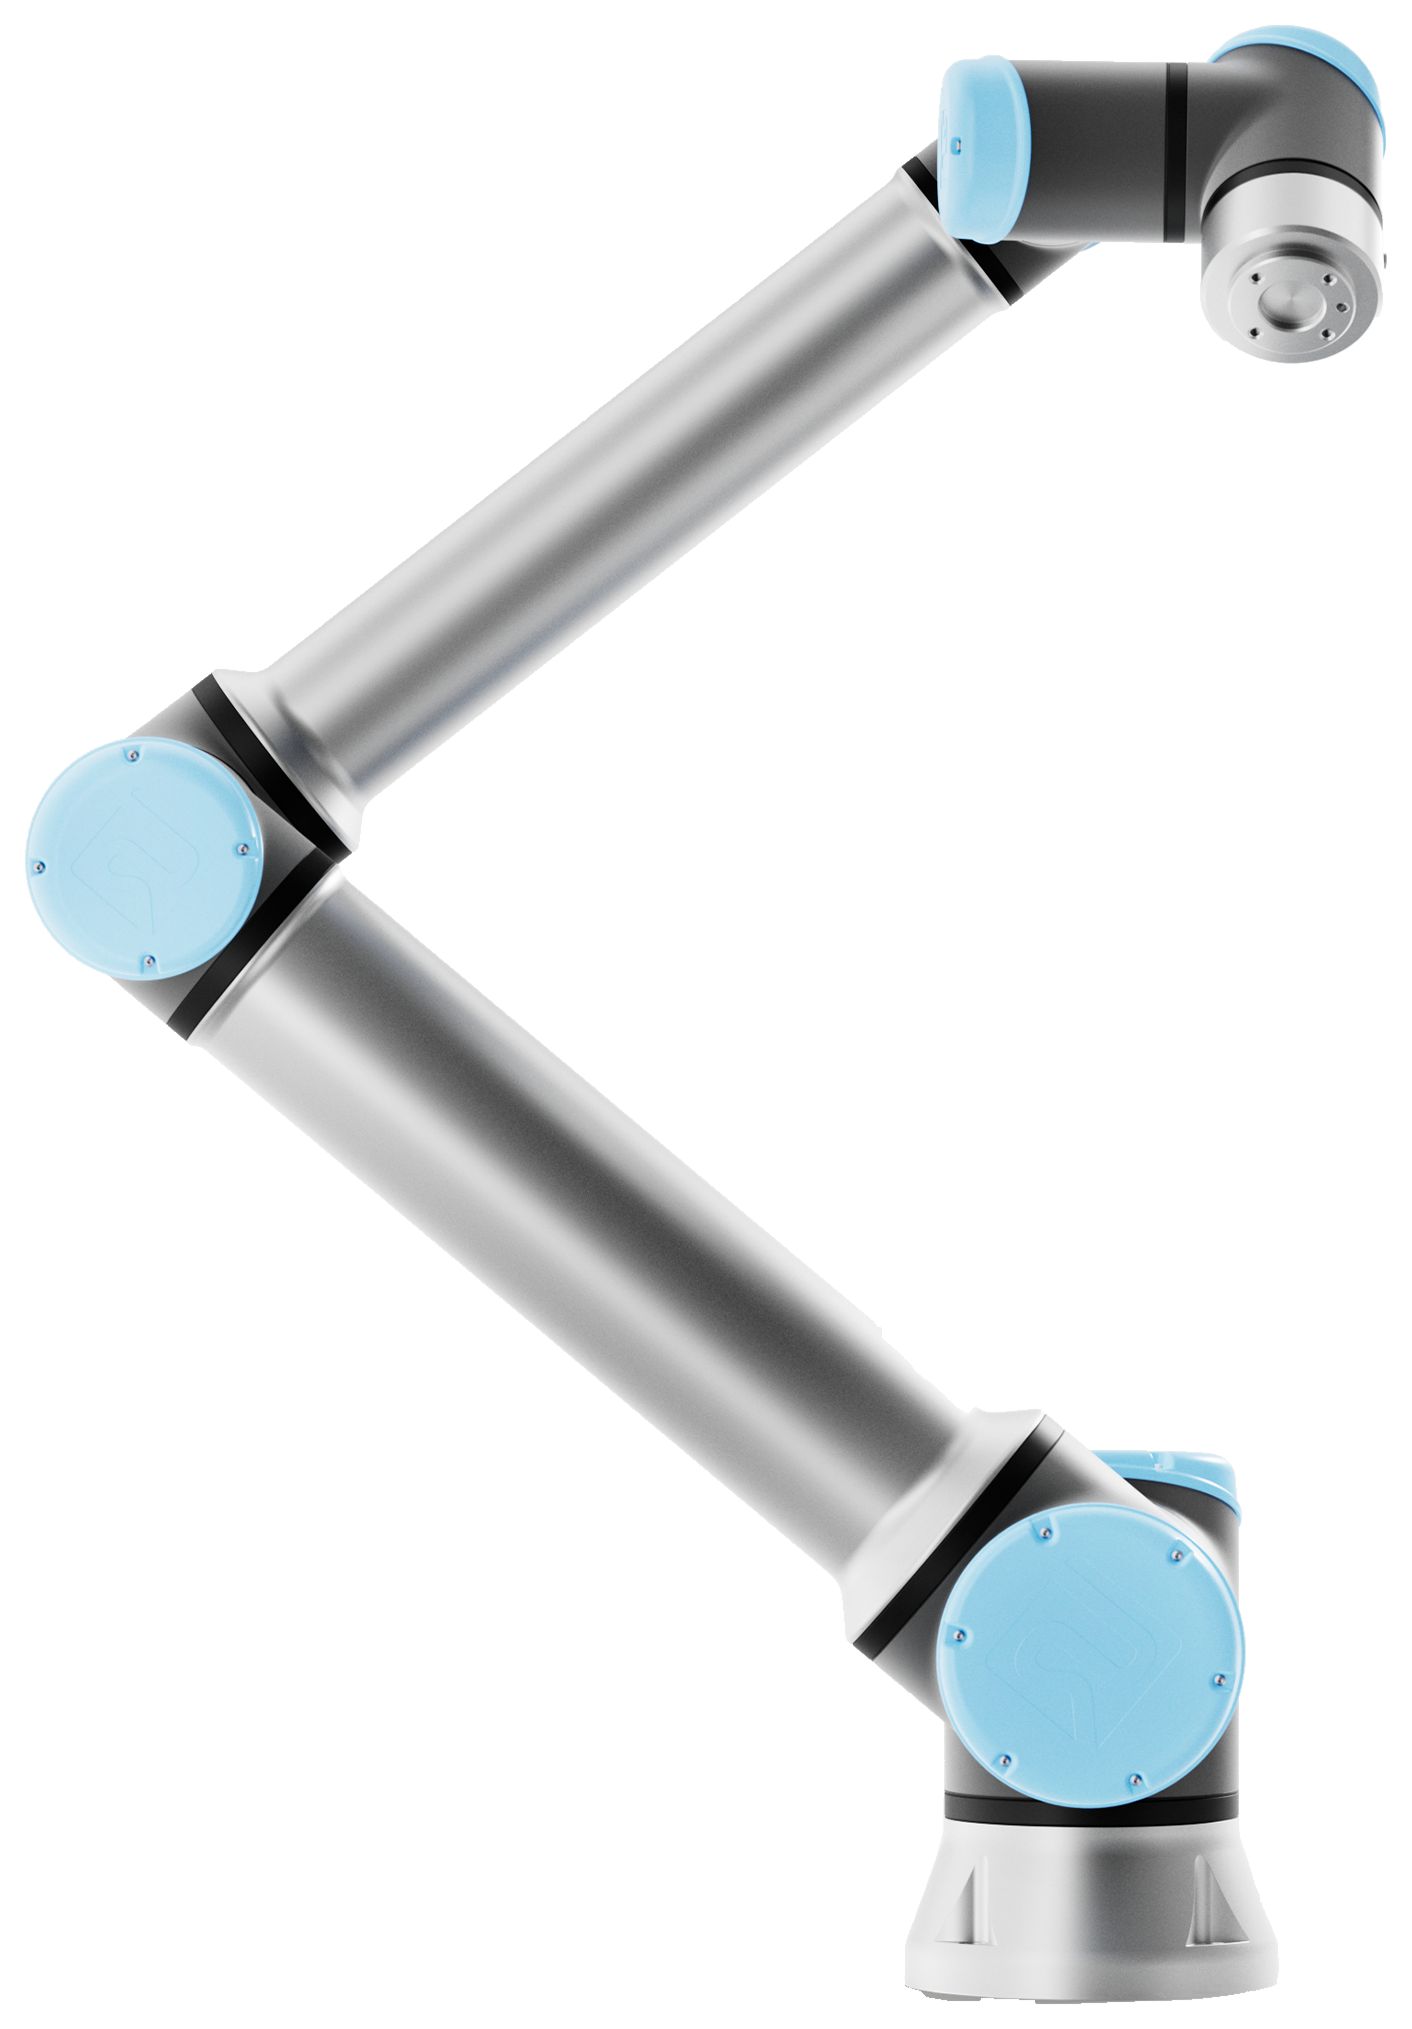
Universal Robots
A six-axis collaborative arm for precision manipulation, assembly, and robot learning experiments.
Manufacturer configuration shown.
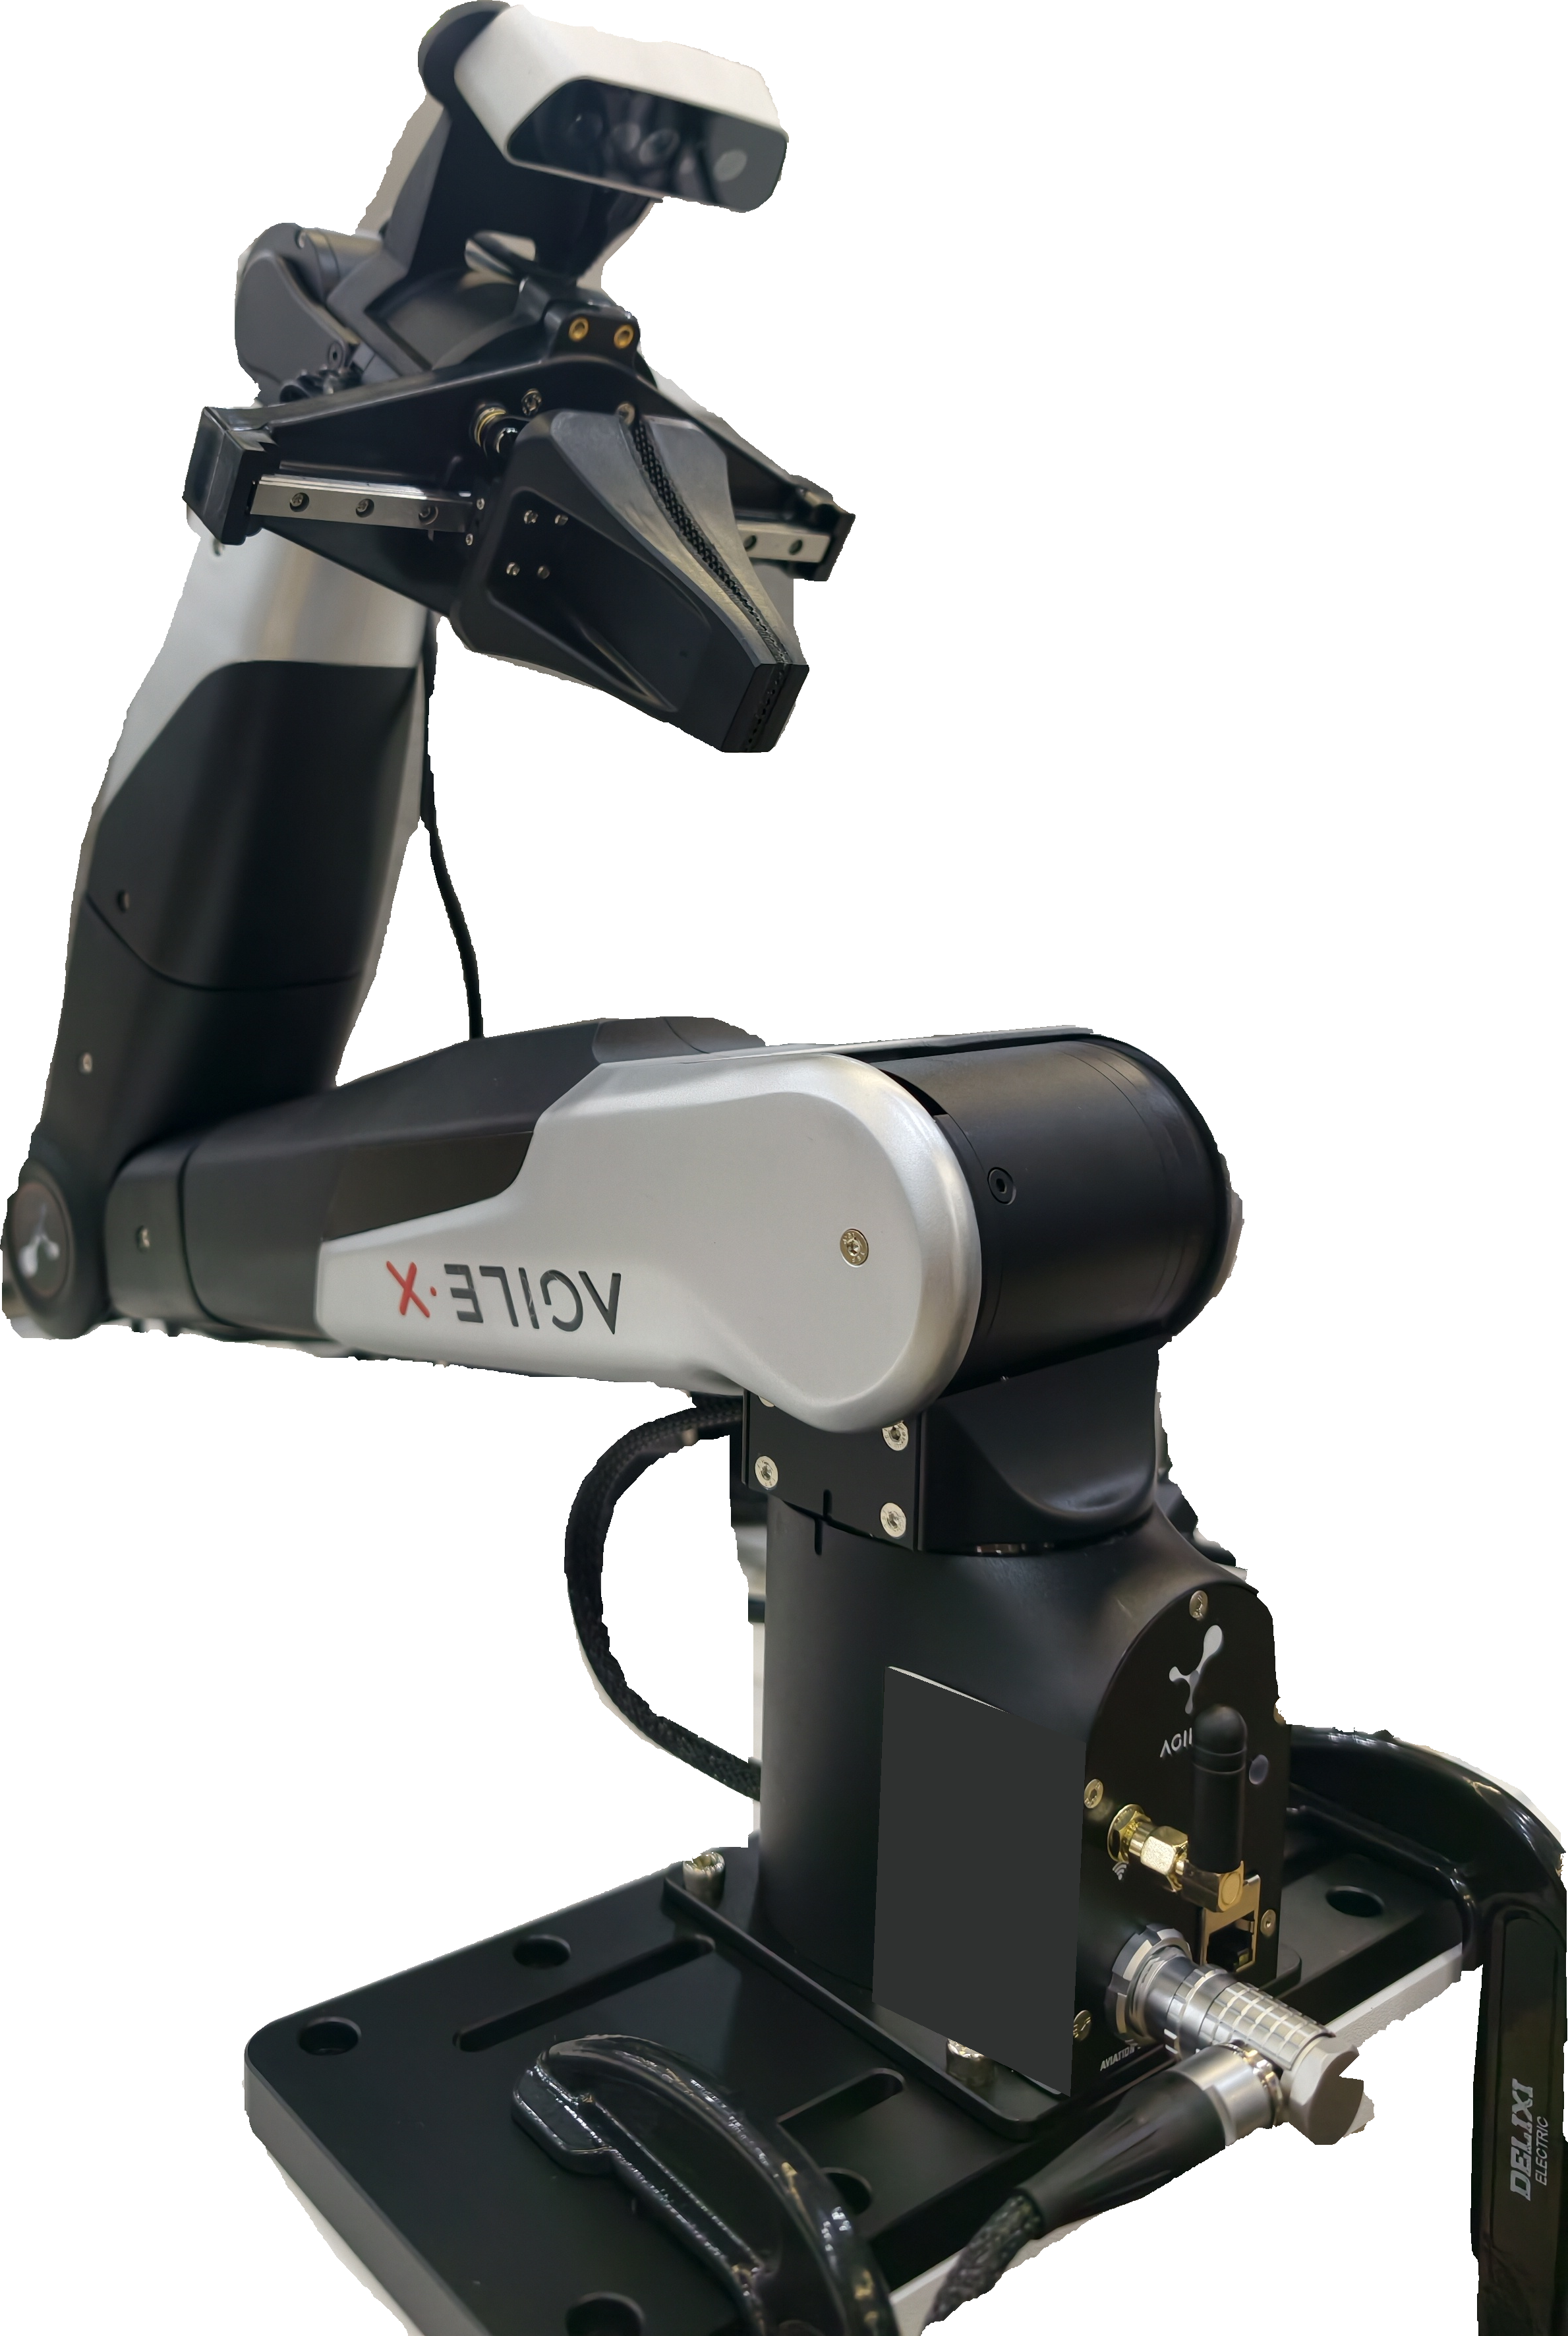
AgileX Robotics
An articulated arm for hand-guided teaching and manipulation research.
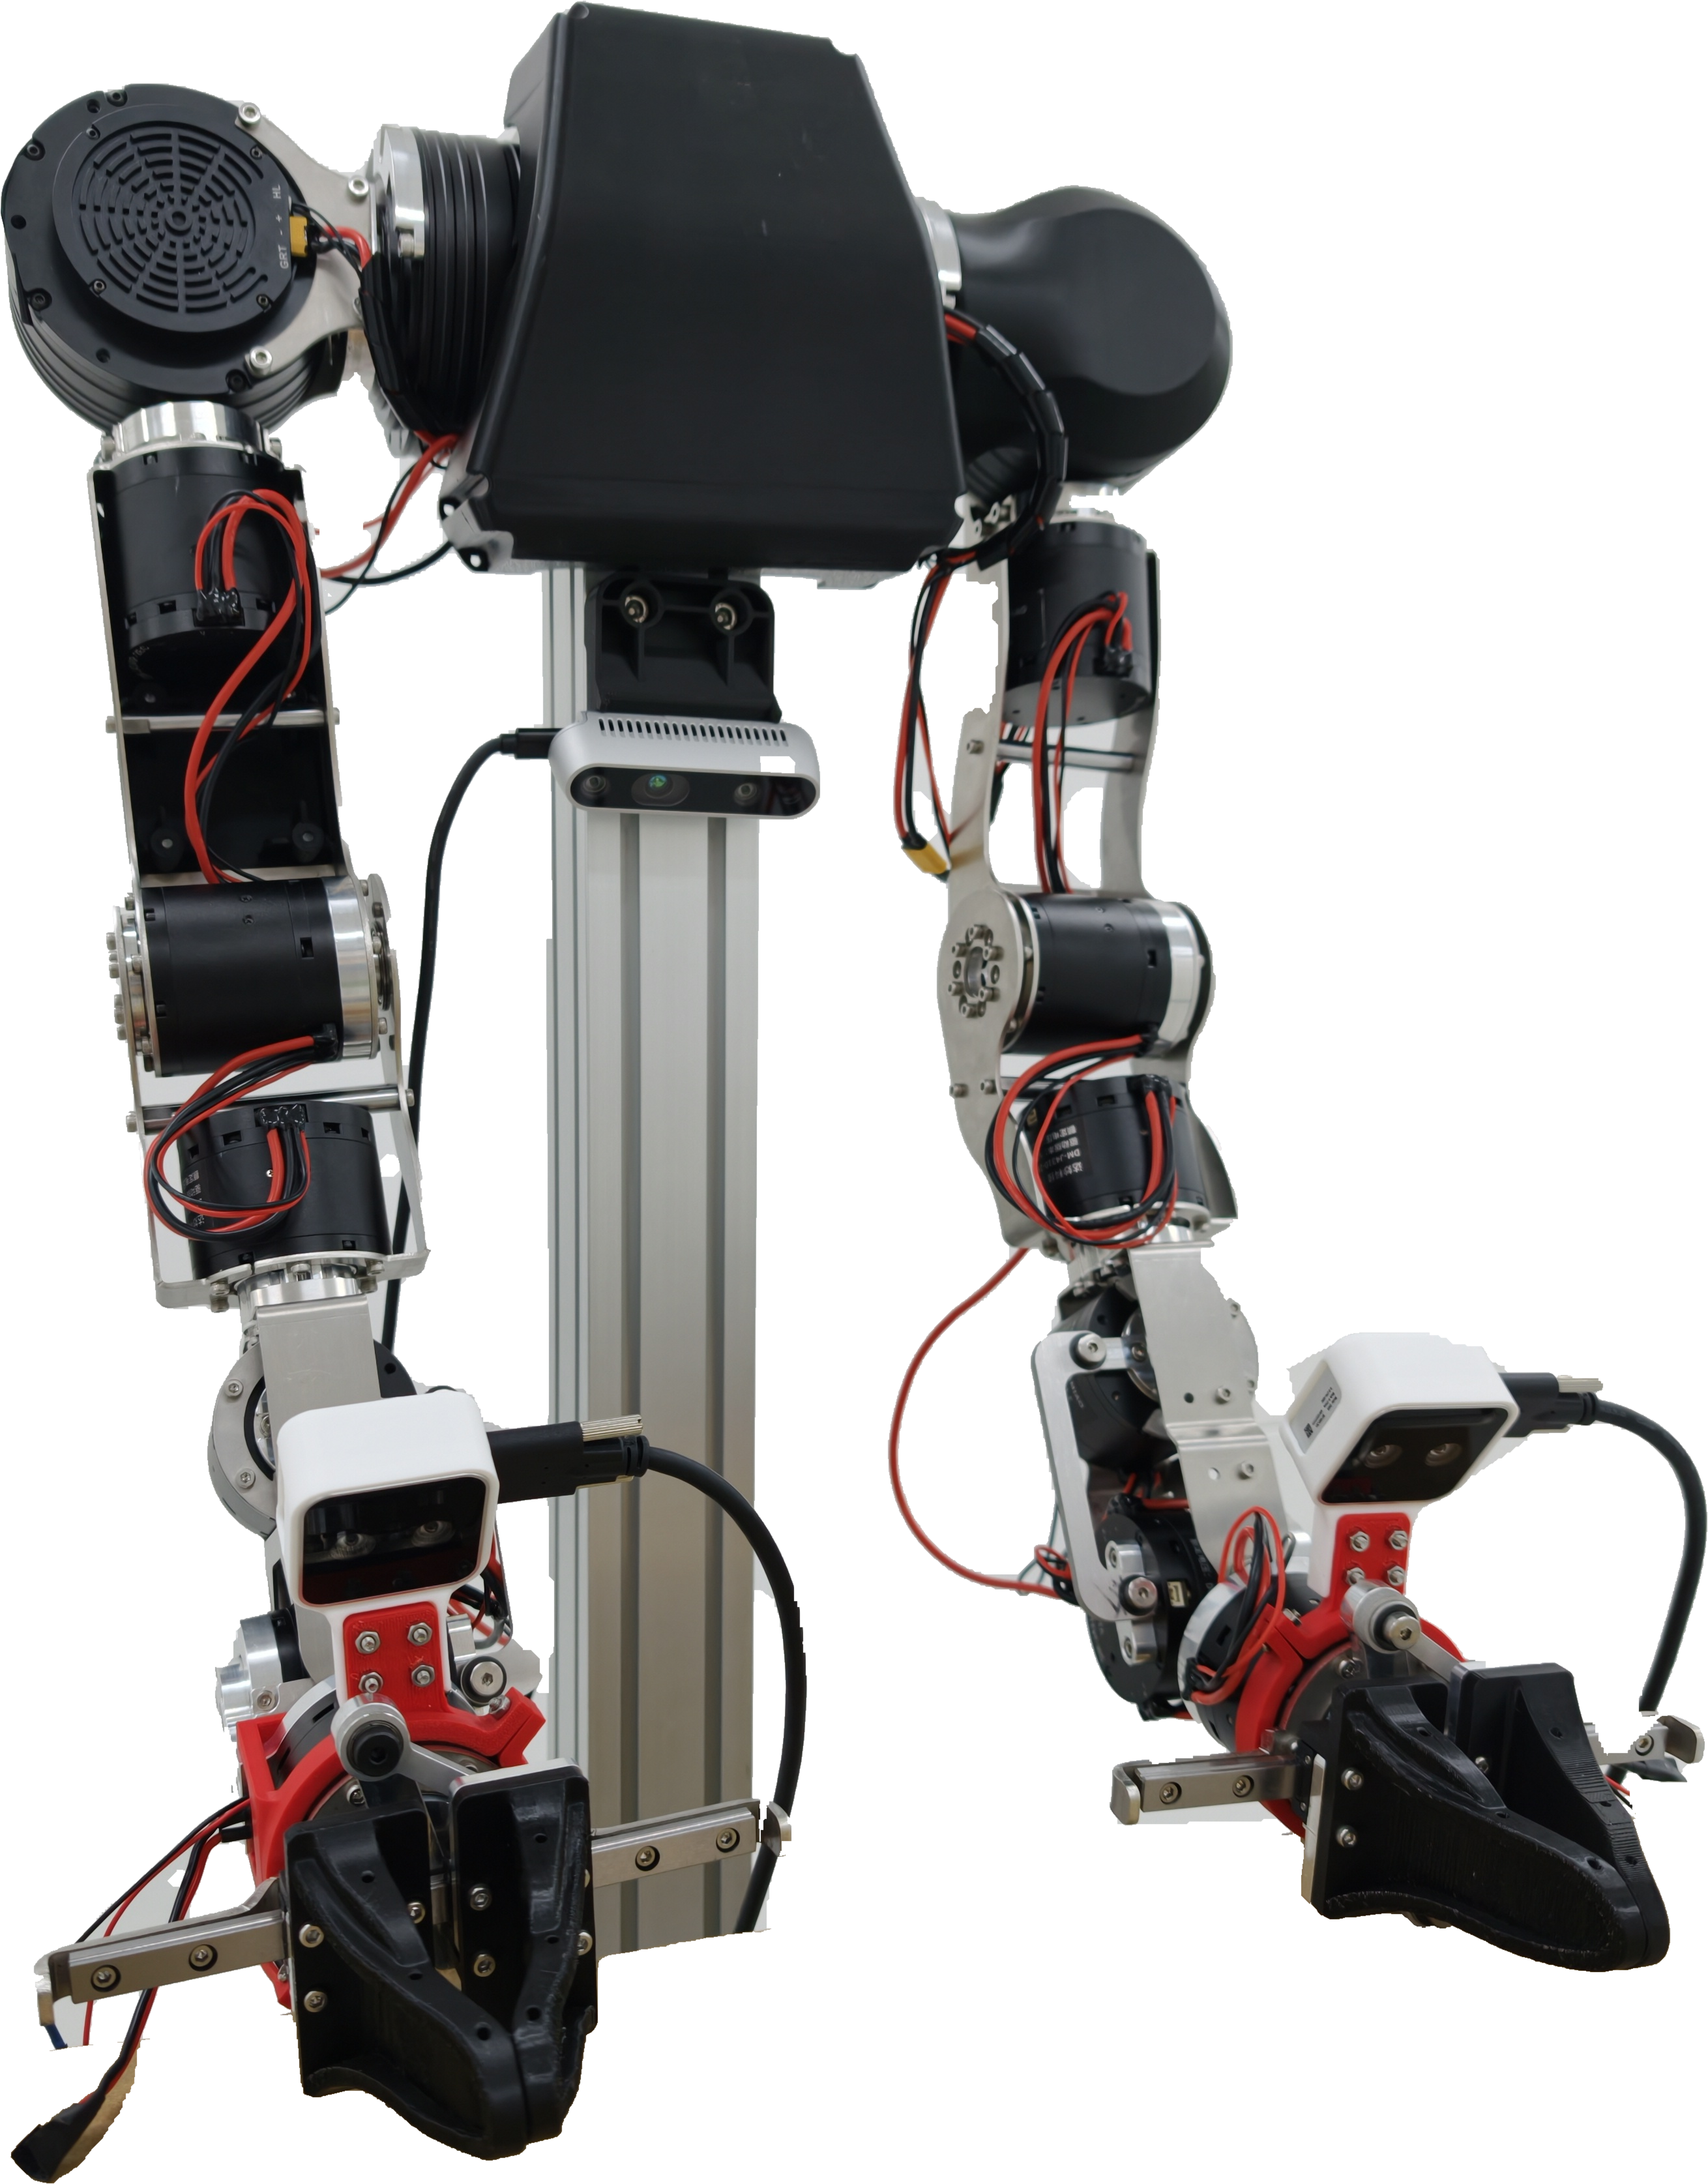
Enactic · Open source
An open-source arm platform for teleoperation and contact-rich manipulation.
Lab dual-arm configuration shown.
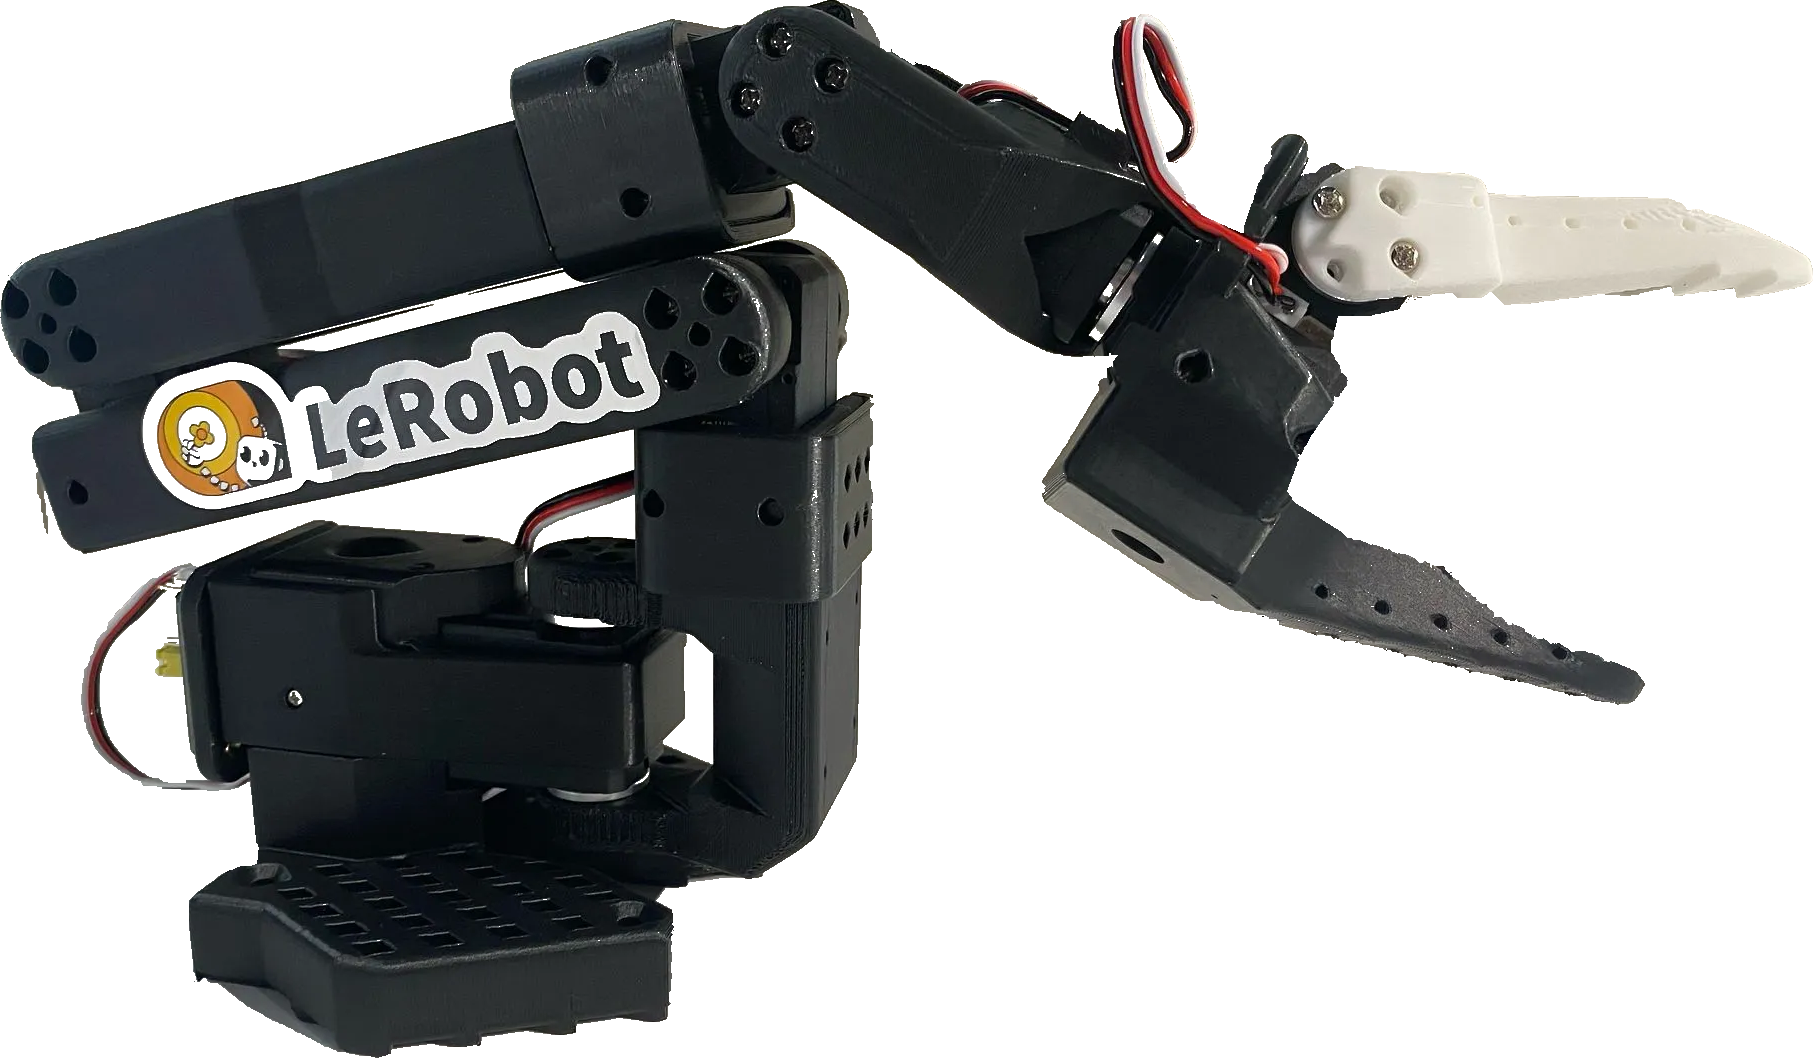
SO-ARM · Open source
A leader–follower arm platform for collecting demonstrations and learning manipulation.
Follower arm shown.
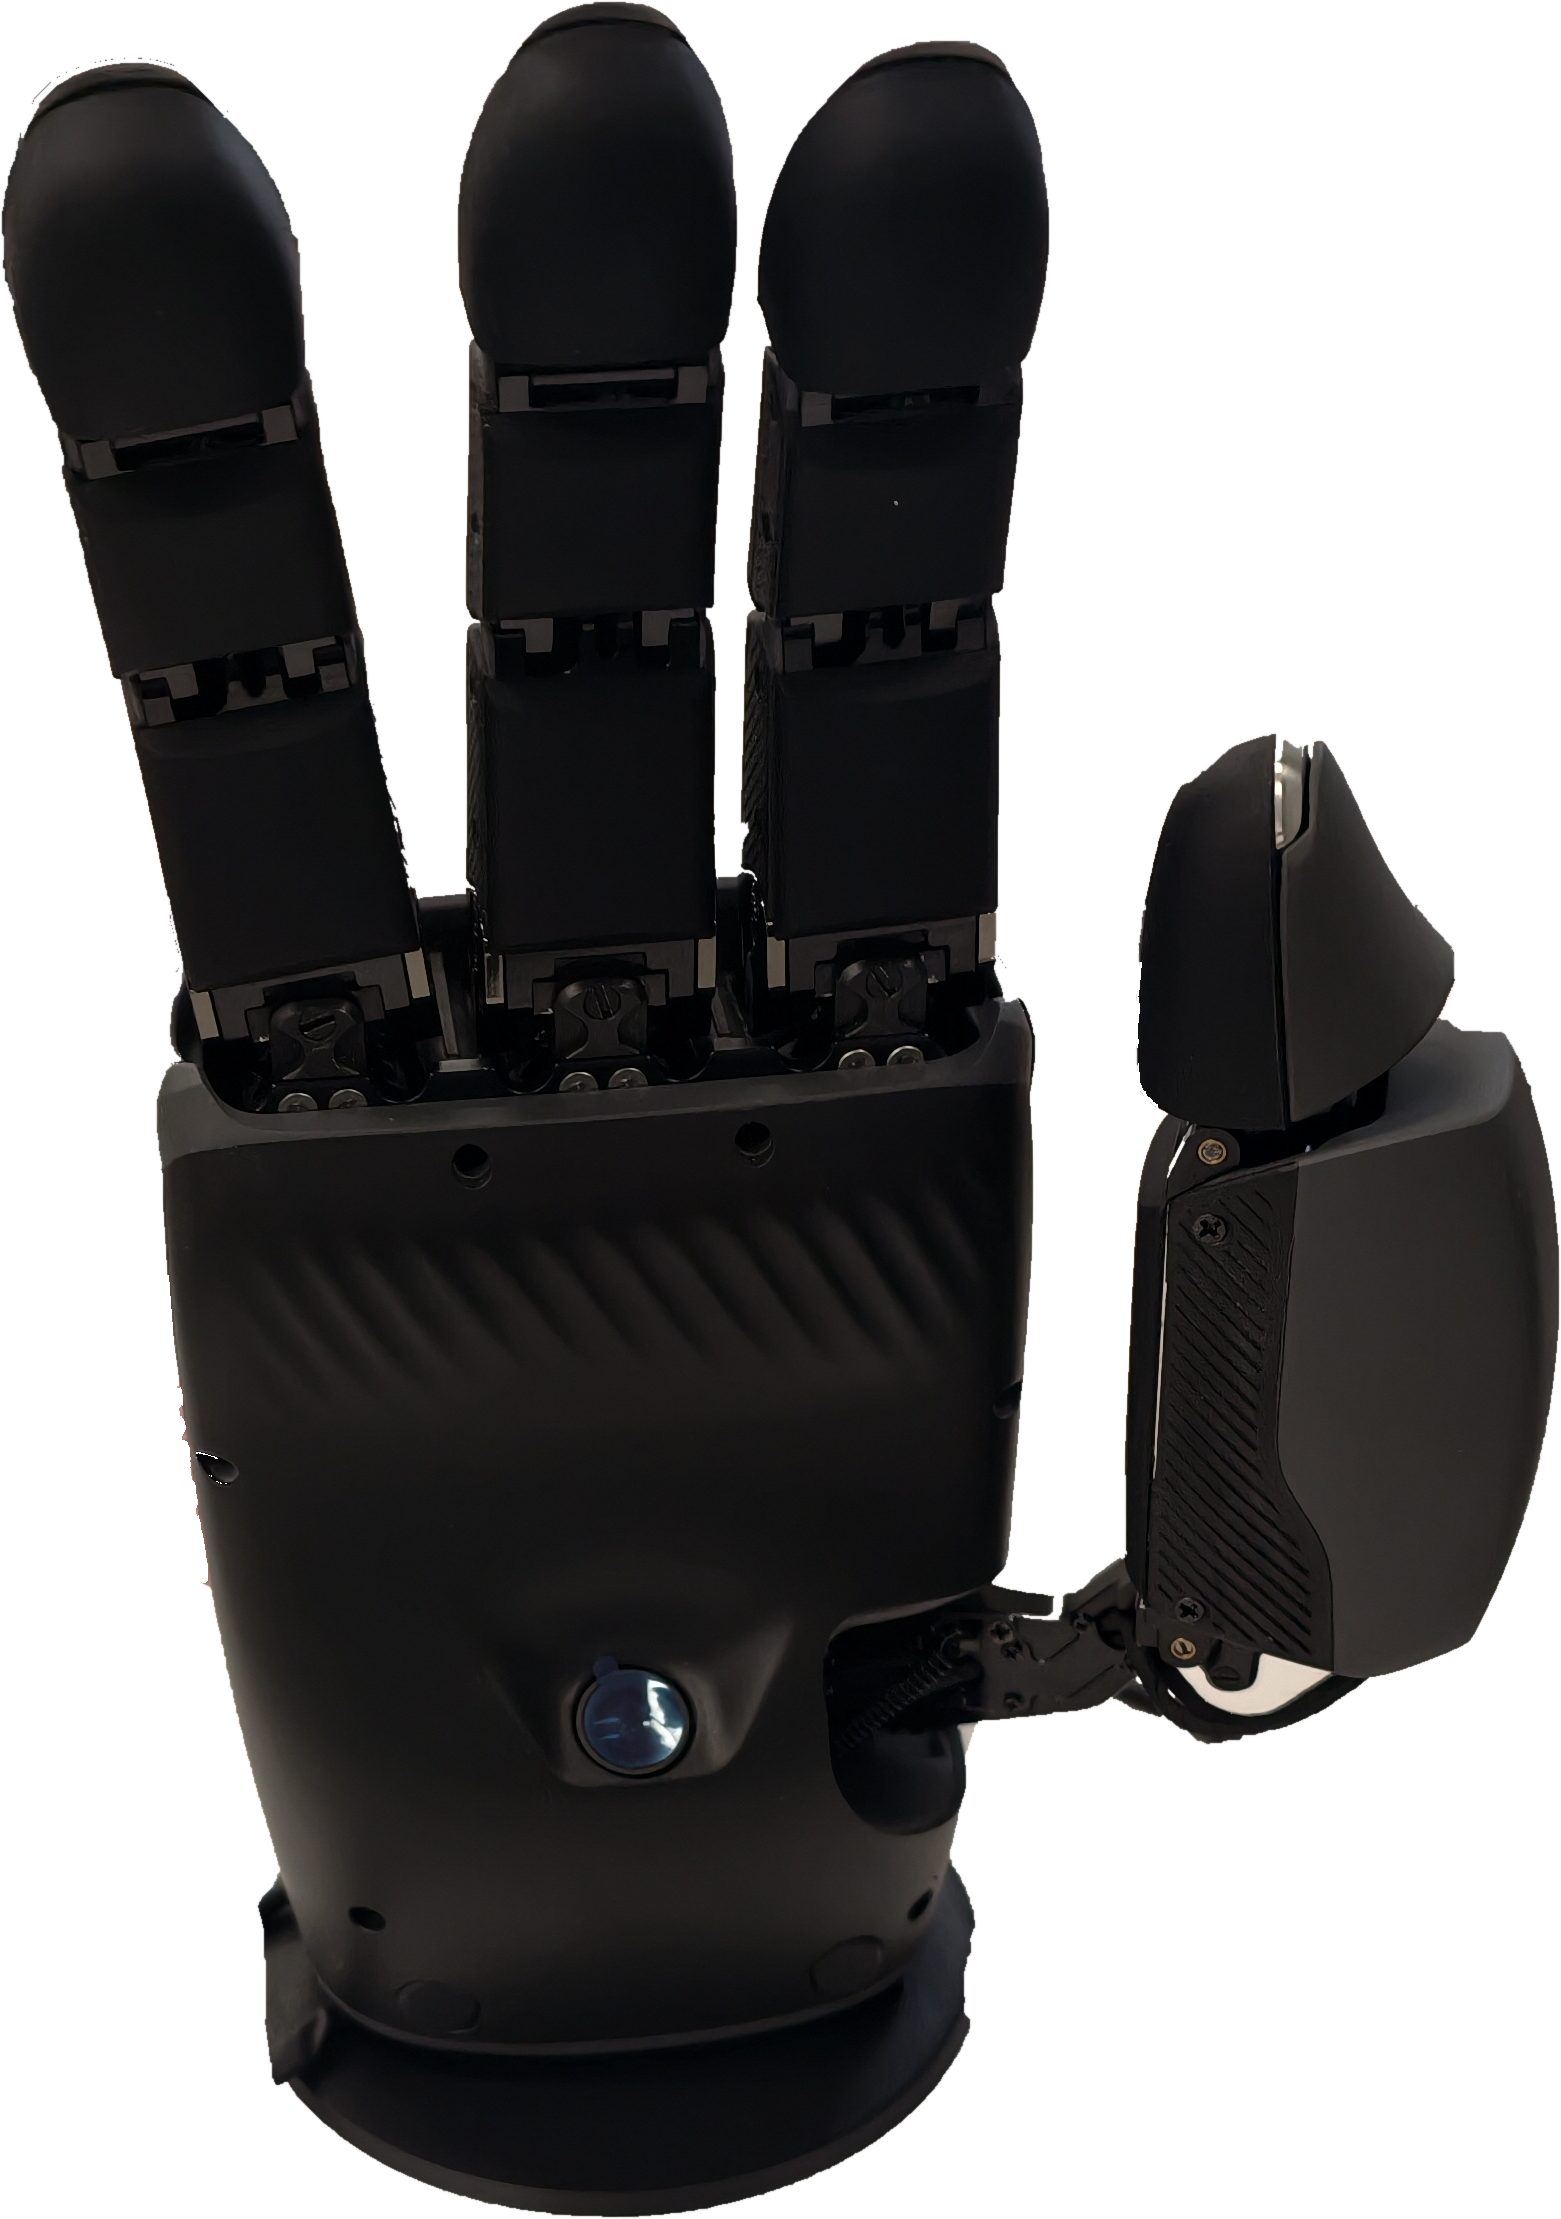
PAXINI
A dexterous hand with integrated tactile sensing for fine manipulation.
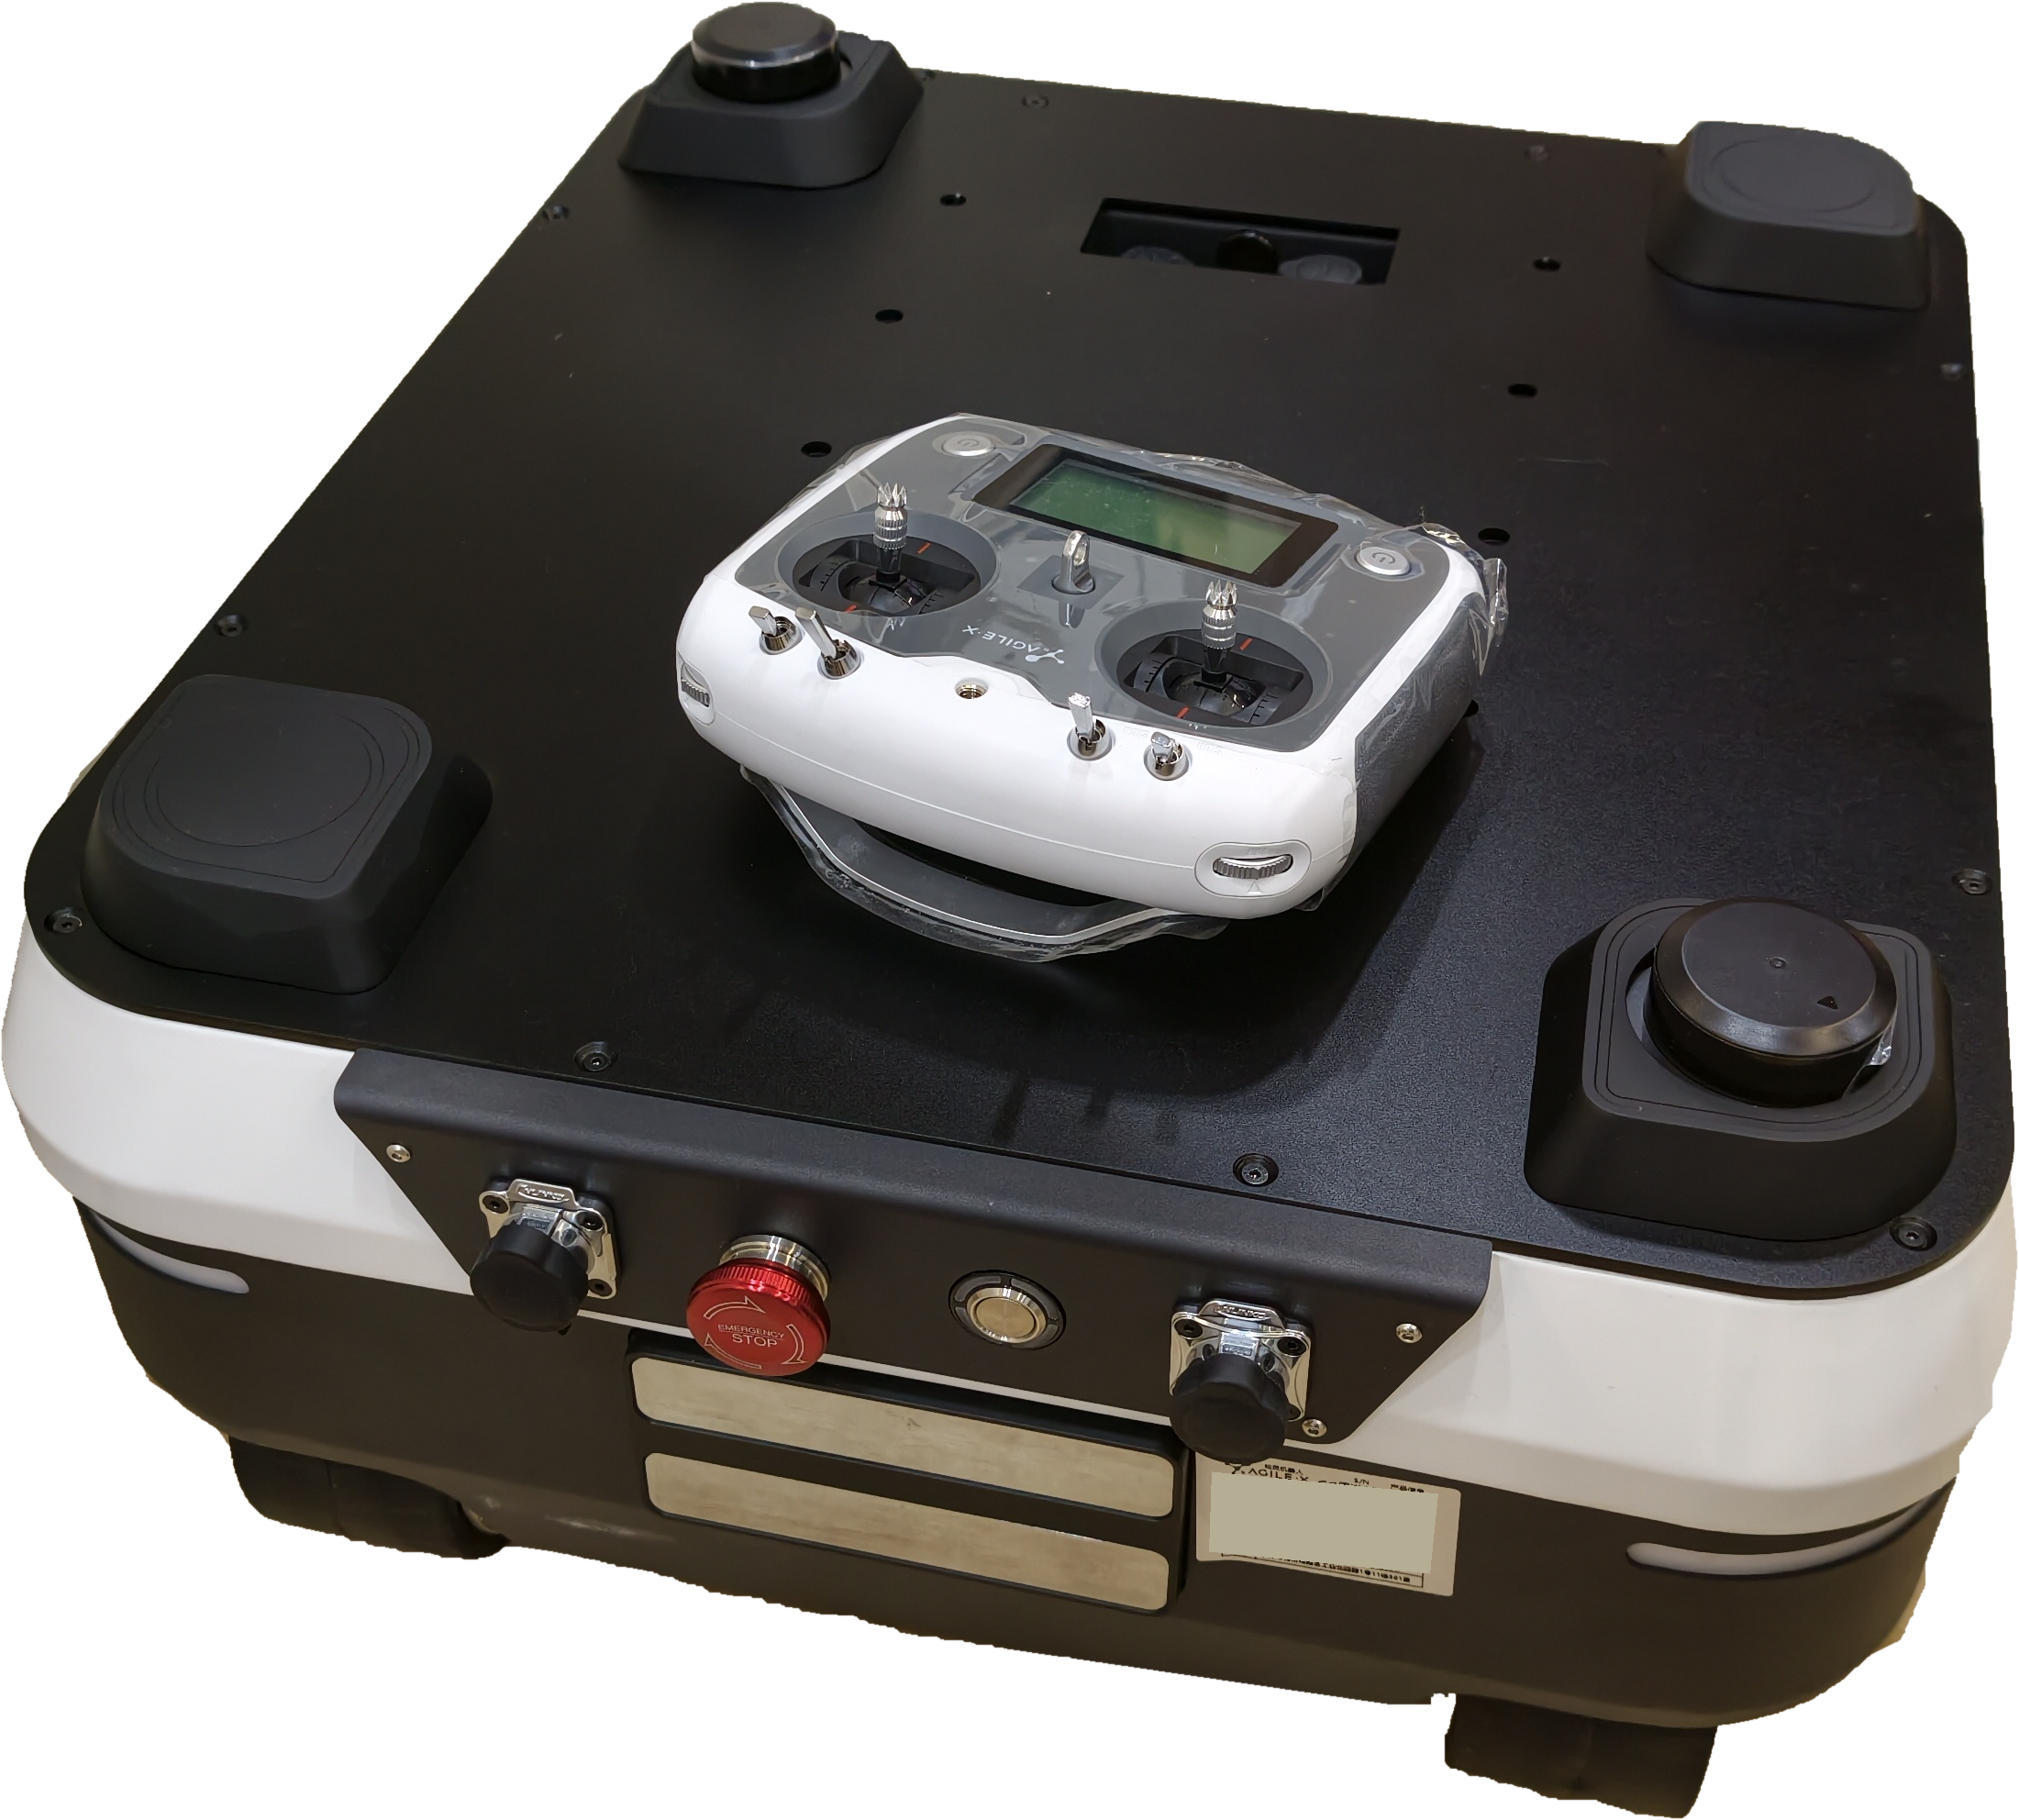
AgileX Robotics
An agile ground platform for navigation and mobile robotics experiments.
Embodied platforms connecting locomotion, manipulation, and real-world data.
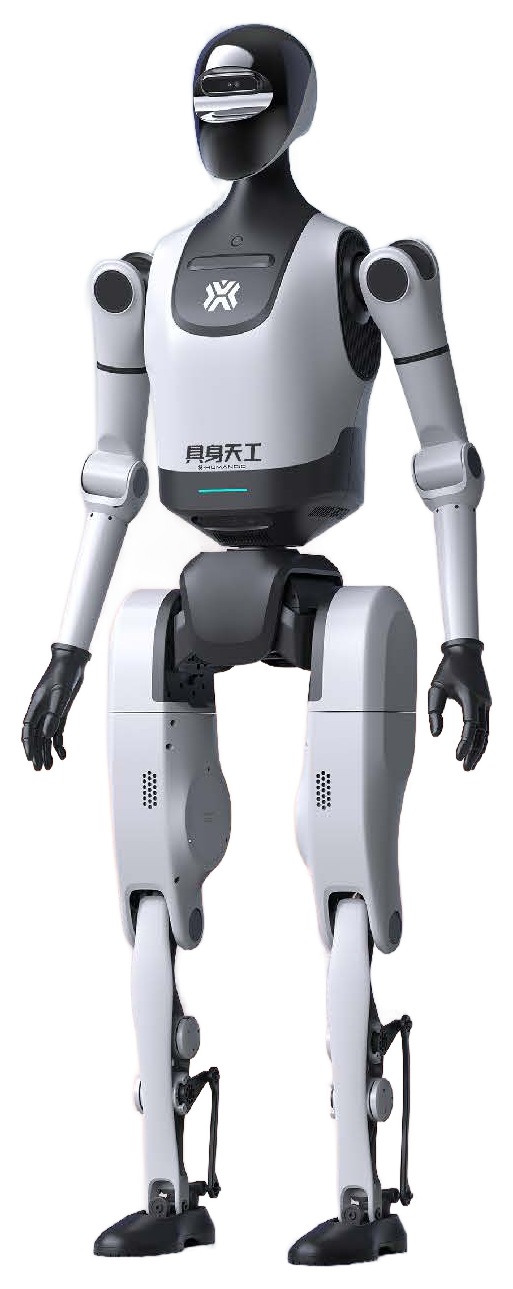
X-Humanoid
Tiangong Plus, Pro, and a data collection station for embodied intelligence research.
Tiangong 2.0 manufacturer configuration shown; configurations vary.
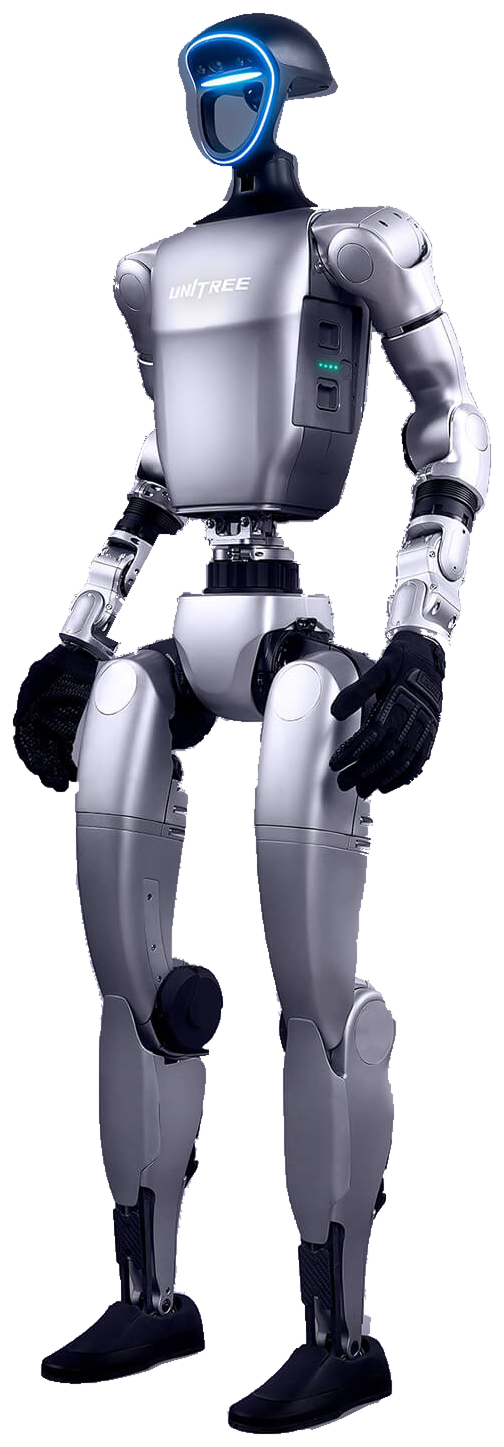
Unitree Robotics
A compact humanoid platform for studying whole-body movement and interaction.
Manufacturer configuration shown; configurations vary.
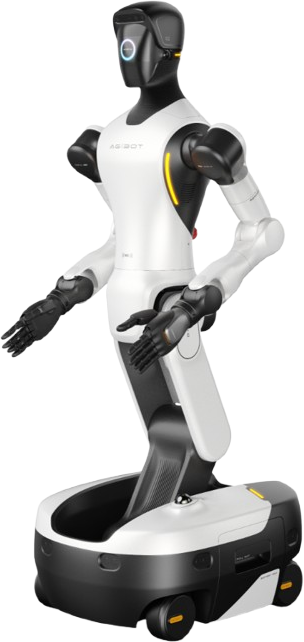
AGIBOT
A mobile dual-arm platform for manipulation, teleoperation, and embodied learning.
Immersive interfaces and motion capture for demonstrations and human–robot interaction.
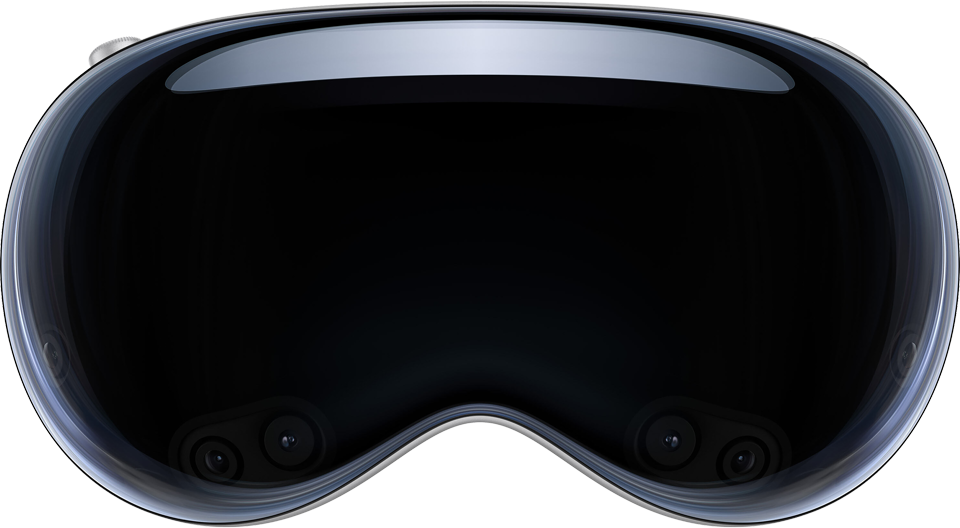
Apple
An immersive interface for spatial interaction and robot teleoperation.
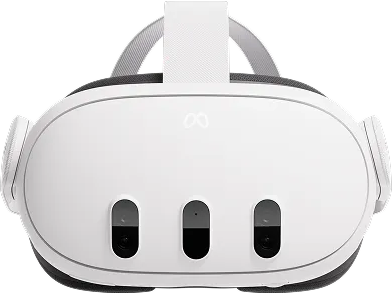
Meta
A mixed reality interface for immersive interaction and teleoperation.
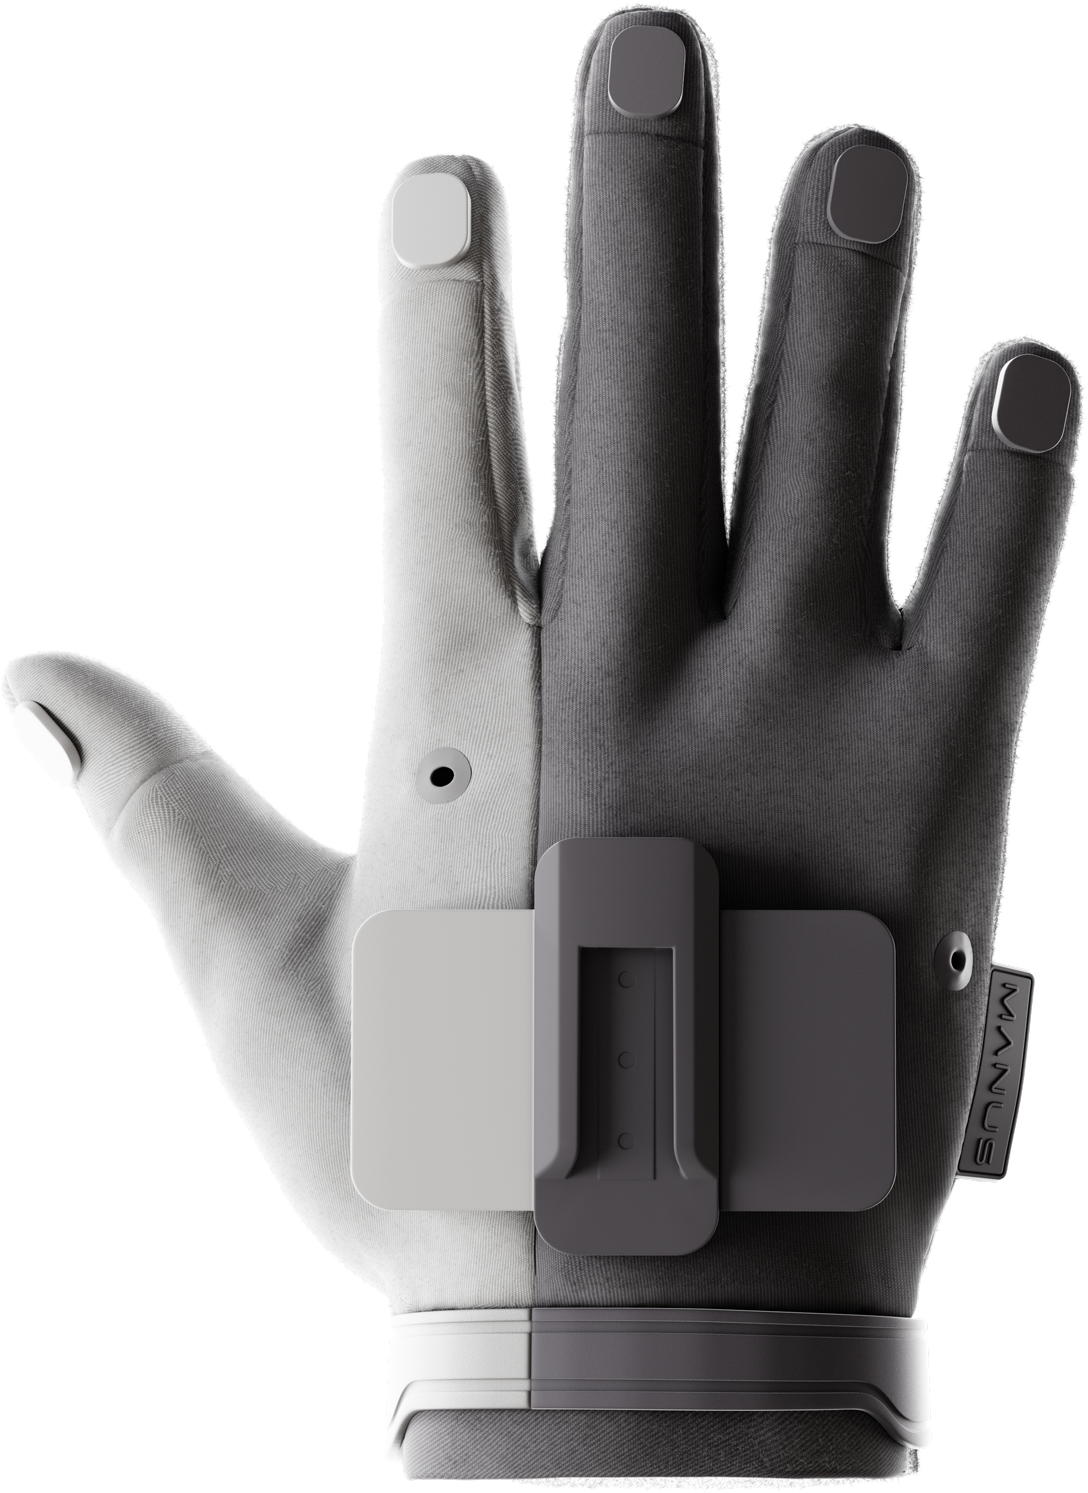
MANUS
EMF motion-capture gloves for recording hand motion and collecting dexterous teleoperation demonstrations.
One glove shown.
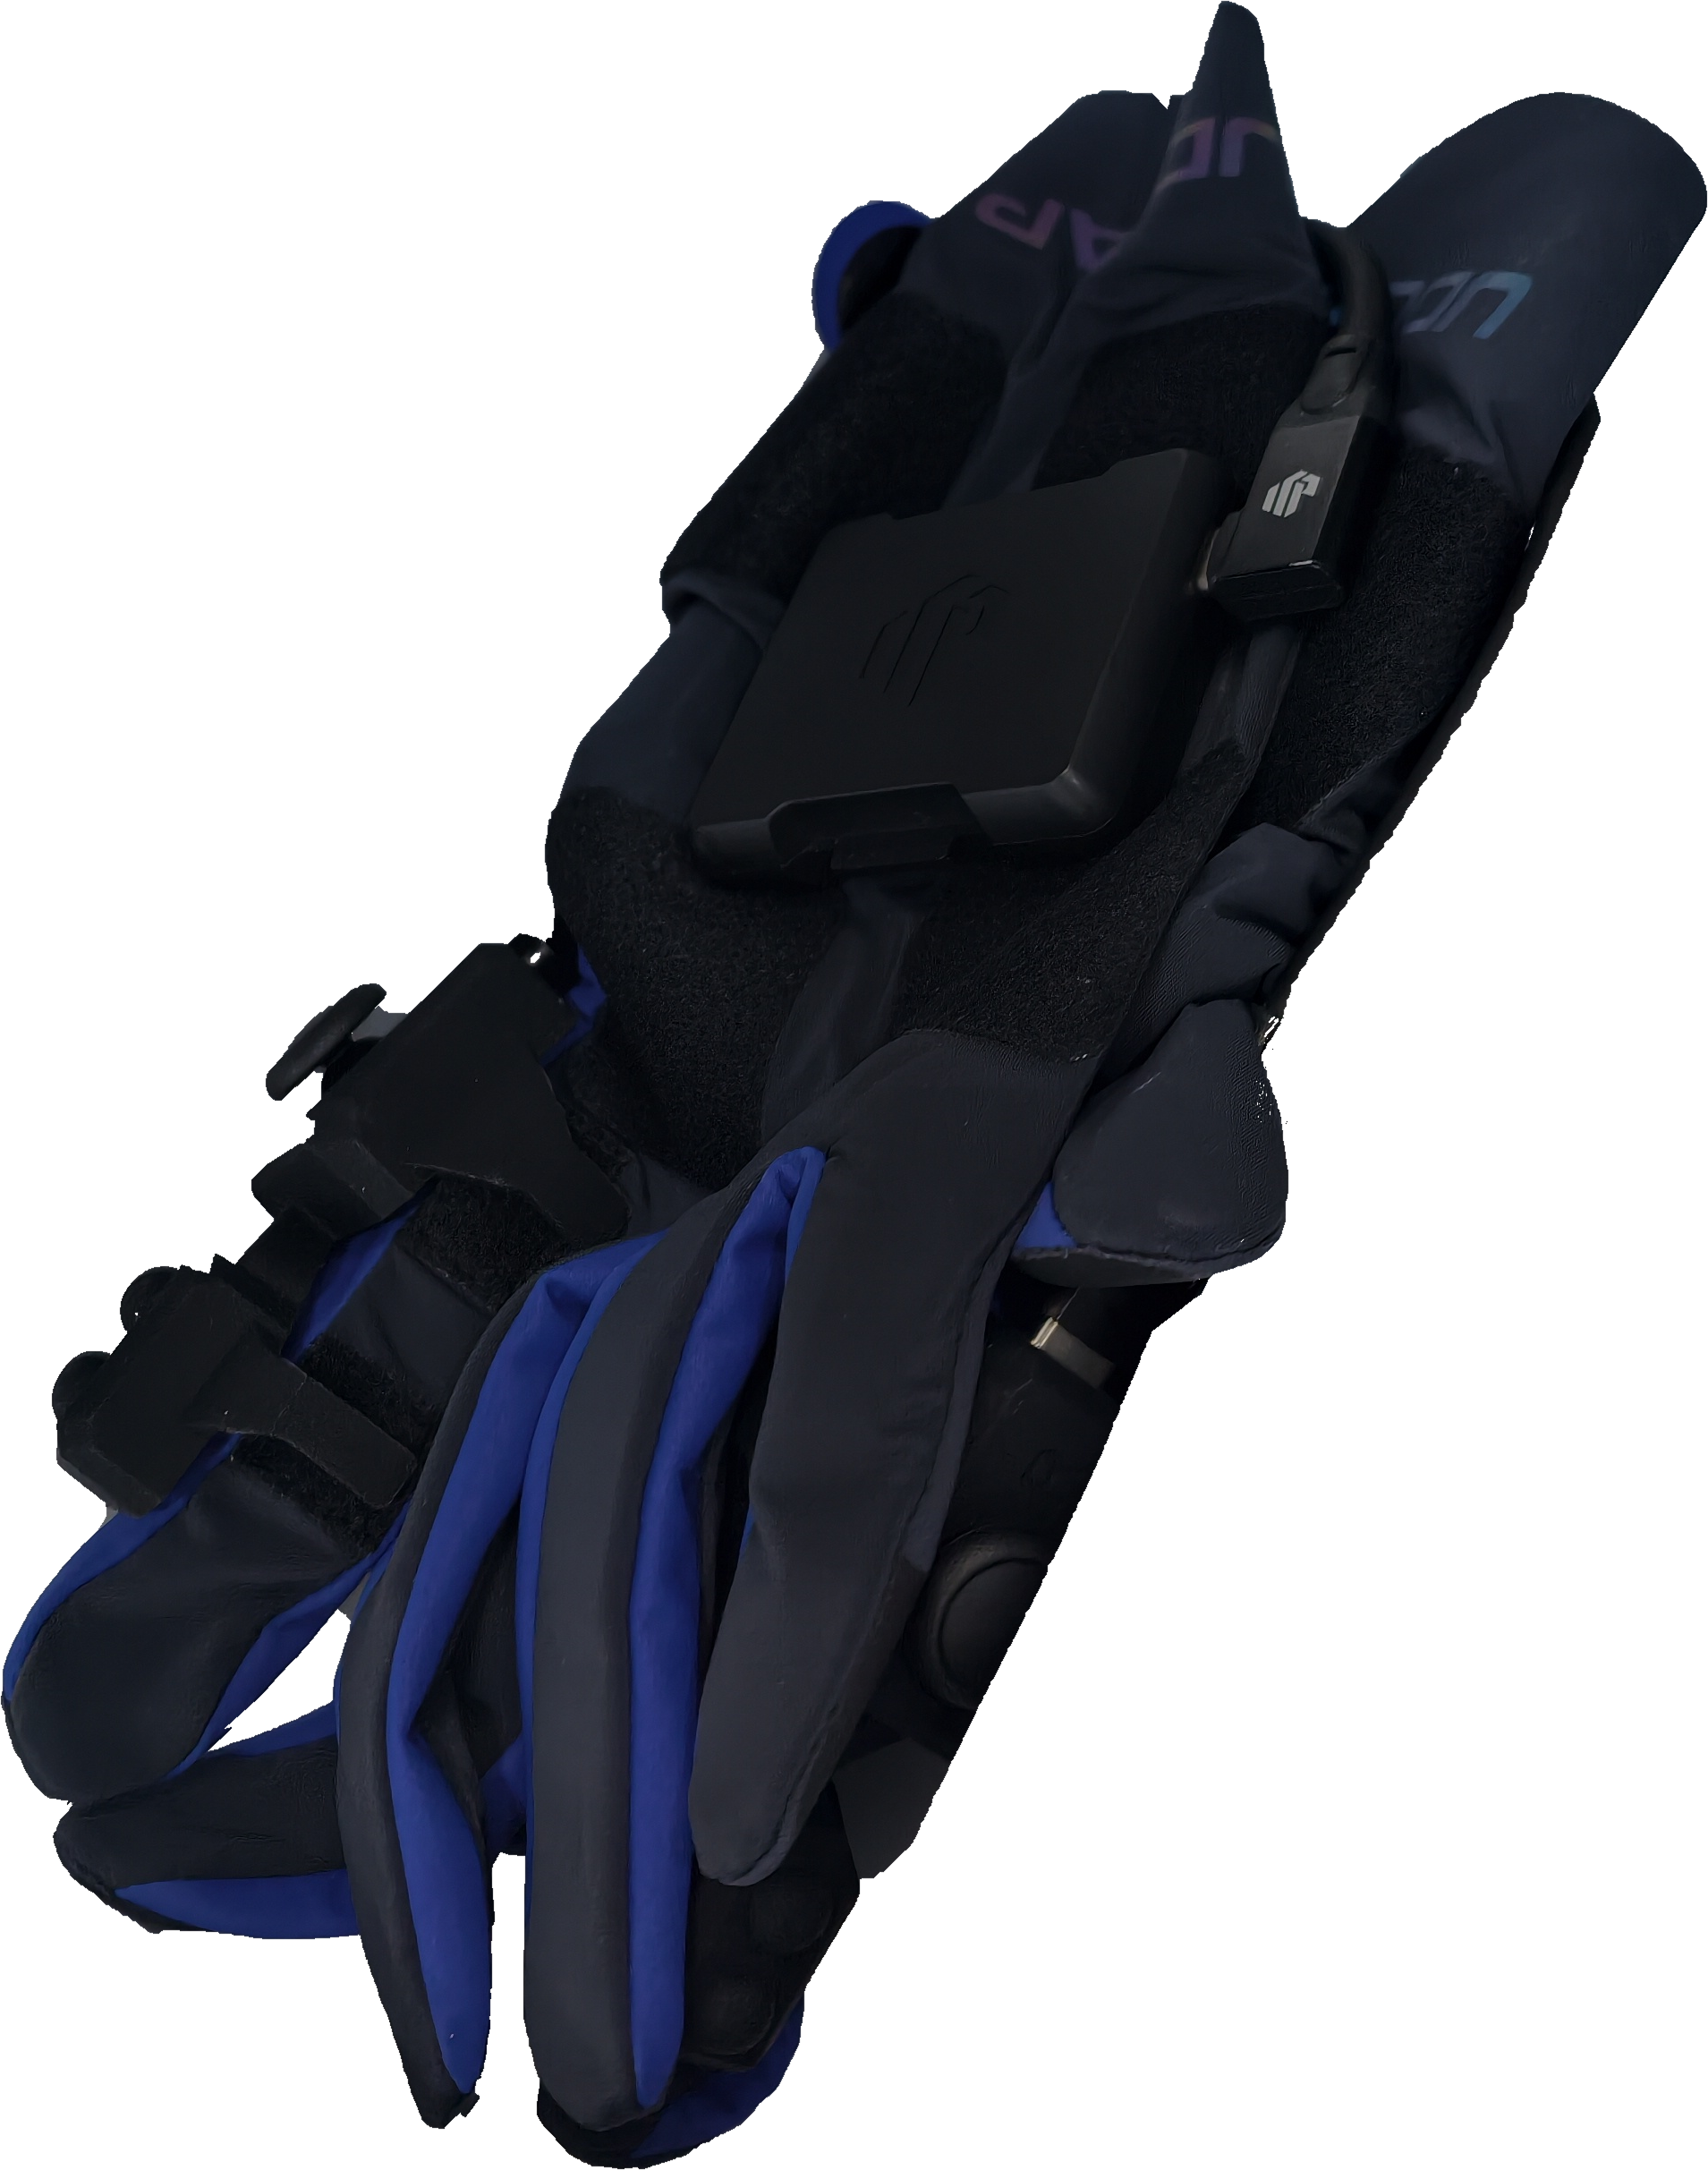
UDEXREAL
Wearable gloves for recording hand motion and collecting demonstrations.
Computing infrastructure for AI training, simulation, and deployment from workstations to the edge.
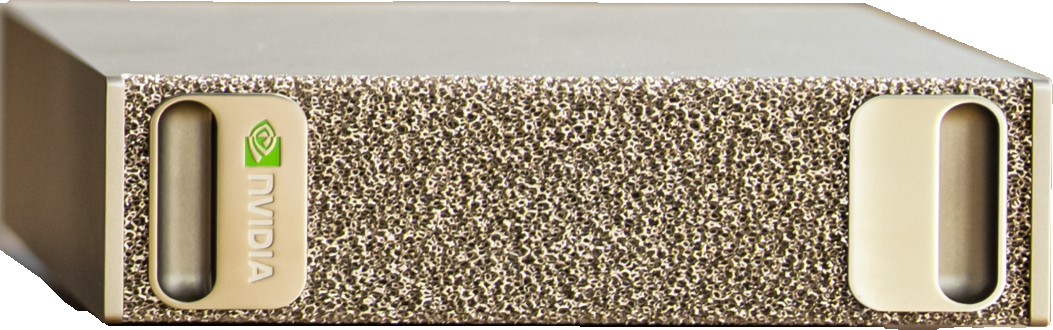
NVIDIA
A compact computing platform for local AI model development and experimentation.
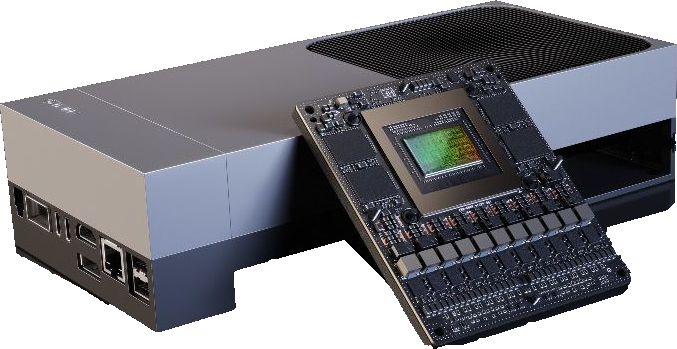
NVIDIA
An edge computing platform for perception and embodied AI workloads.
Developer kit and module shown.
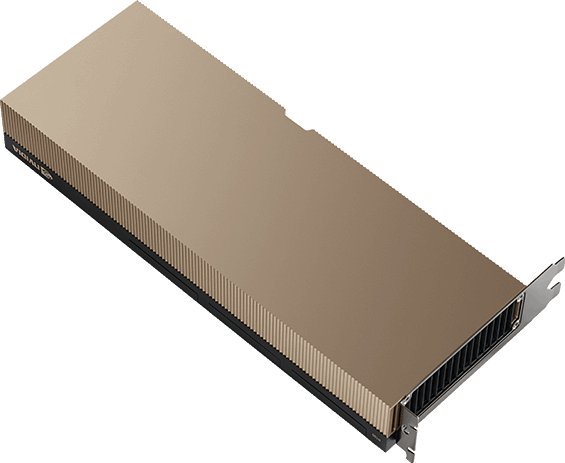
NVIDIA
GPU cluster for training and evaluating large-scale AI models.
H100 GPU shown; cluster configuration varies.
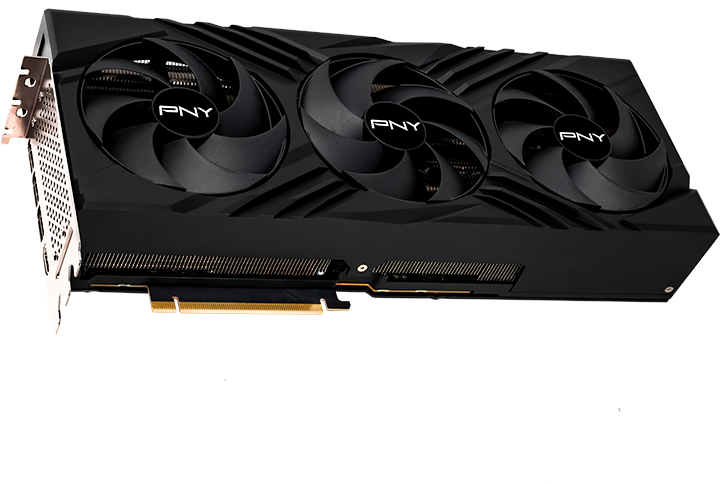
NVIDIA
GPU workstations for model development, simulation, and experimentation.
PNY RTX 4090 shown; board configuration varies.